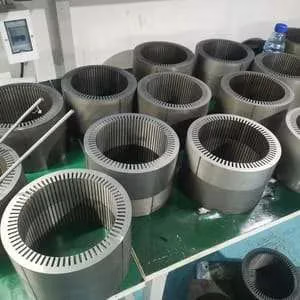
brushless motor
Advantages of Axial Flux Motor Structure
Axial flux motor rotation and linear actuator: the core power unit of humanoid robots
As humanoid robots continue to evolve, their ability to move smoothly, precisely, and efficiently has become a key measure of technological maturity. At the center of this capability lie actuators. In simple terms, rotary and linear actuators together form the core power unit of a humanoid robot. Without them, complex motion would not be possible.
In modern robotics, actuators are not just mechanical parts. Instead, they are integrated systems that combine motors, transmission mechanisms, sensors, and control units. Because of this integration, actuators directly determine a robot’s strength, speed, precision, and reliability. Therefore, understanding actuators is essential for anyone involved in humanoid robot development, manufacturing, or investment.
This article provides a comprehensive overview of rotary actuators, linear actuators, electric motors, and axial flux motors. At the same time, it explains why axial flux motors are becoming a key technology for next-generation humanoid robots and other high-performance drive systems.

1. Actuators: The Foundation of Robot Motion
Actuators are the components that make robots move. In general, an actuator converts electrical energy into mechanical motion. As a result, it enables joints to rotate, arms to lift, and legs to walk.
From a functional perspective, actuators can be divided into two main types:
-
Rotary actuators
-
Linear actuators
This classification is based on the transmission method used to generate motion.
1.1 What Is an Actuator?
An actuator, often called an integrated joint, converts the rotational motion of a motor into controlled movement of a mechanical linkage. In other words, it is the direct power source behind every robot action.
At the same time, the actuator integrates multiple subsystems:
-
a transmission mechanism
-
sensors
Because of this integration, actuators play a central role in motion accuracy, response speed, and energy efficiency.
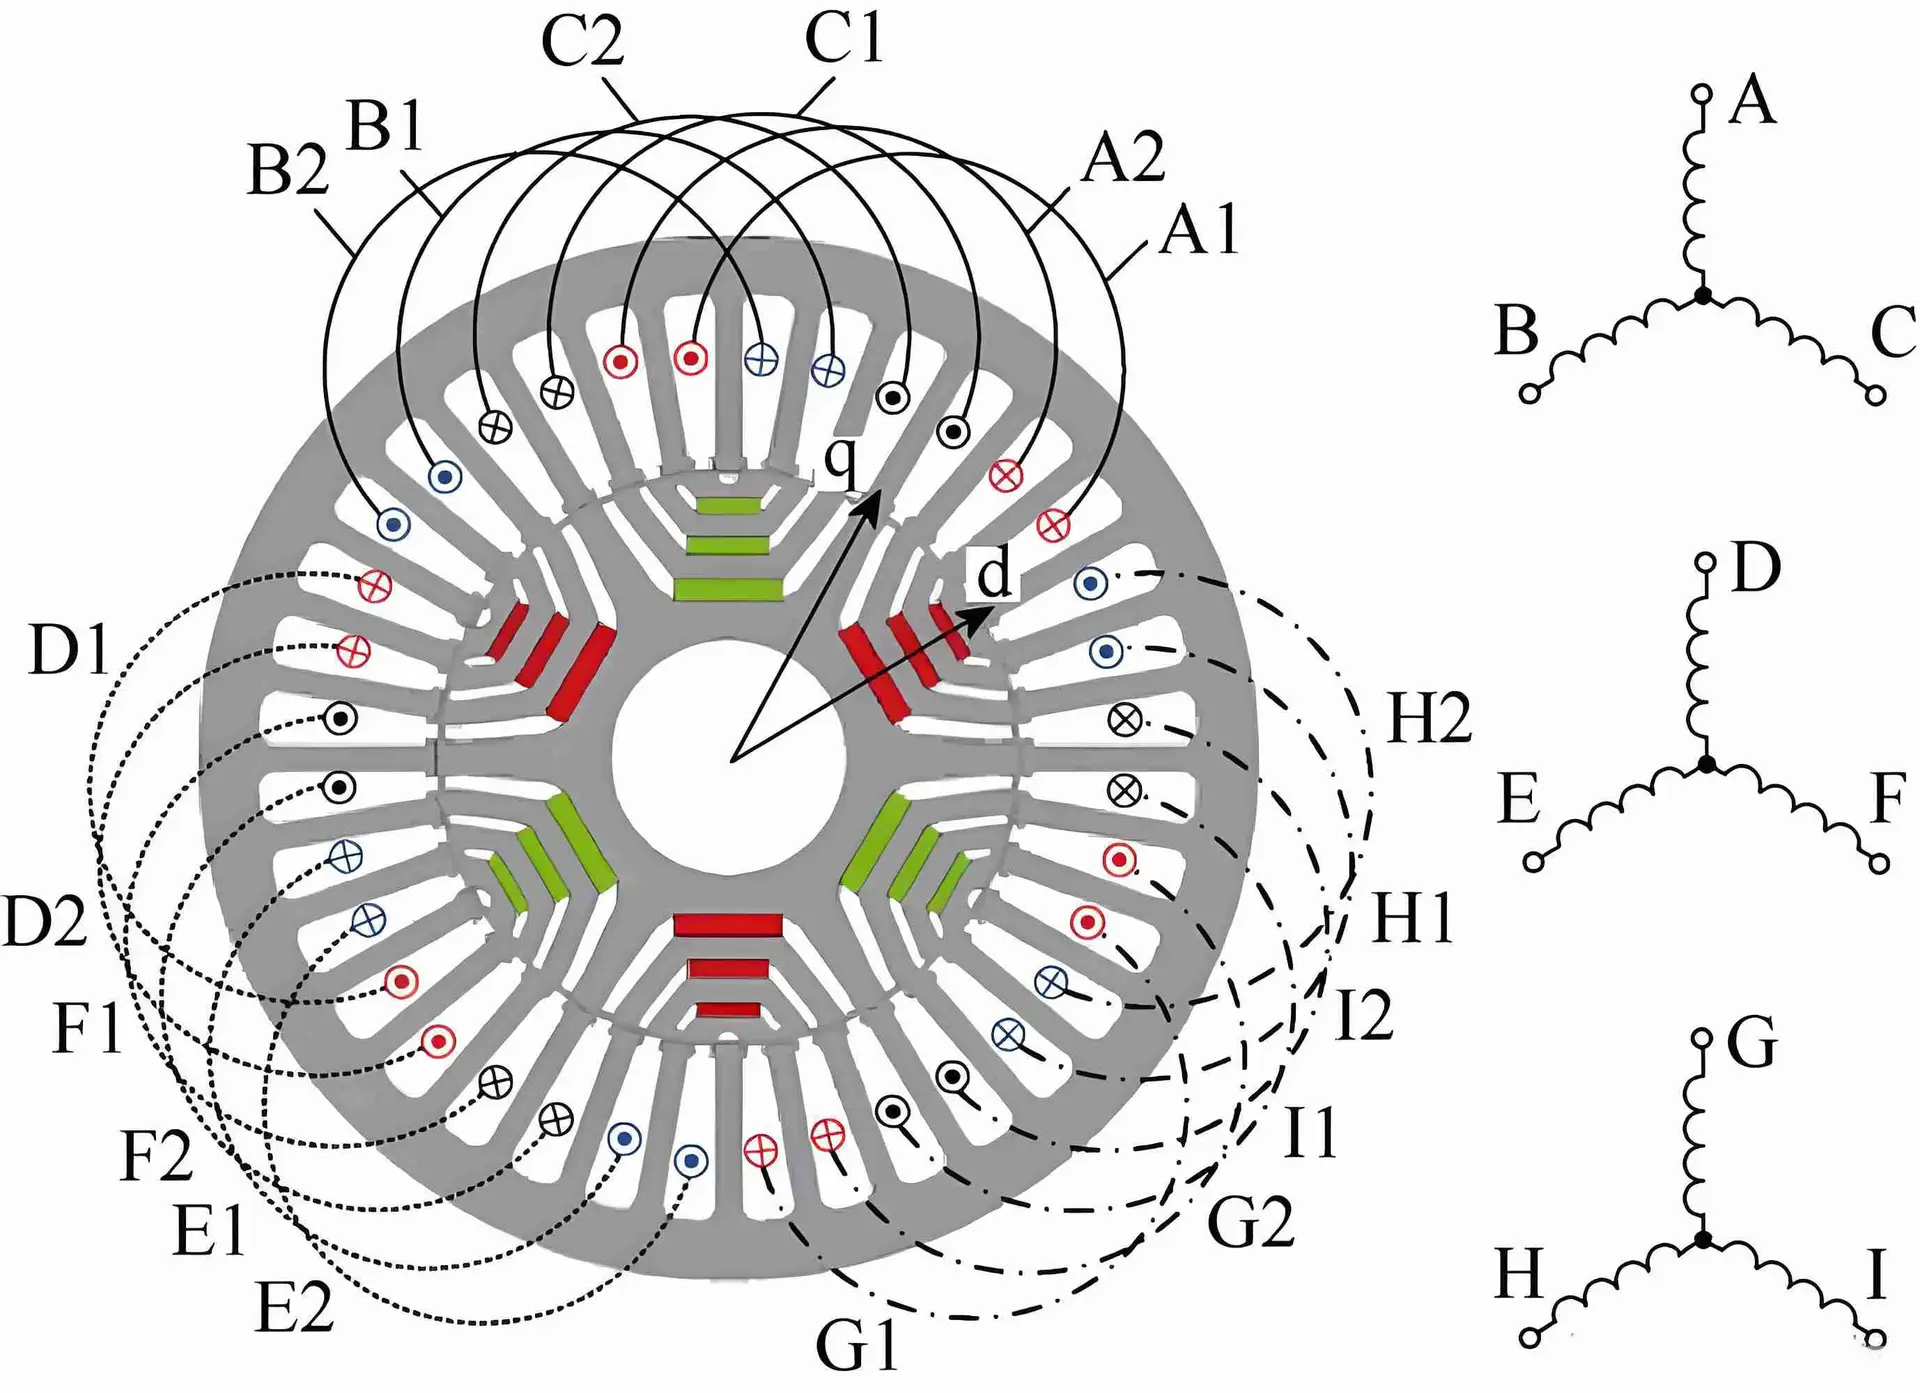
high-torque-density-motors-design
2. Rotary Actuators vs. Linear Actuators
Although both actuator types serve the same purpose—motion generation—their working principles are different.
2.1 Rotary Actuators
Rotary actuators generate rotational motion. Typically, they use a reducer or gearbox to amplify torque while reducing speed.
In practice, rotary actuators are widely used in robot joints such as shoulders, hips, and wrists. Their advantages include:
-
compact structure
-
mature technology
-
high efficiency
-
strong torque output
However, they also face limits in backlash, noise, and long-term wear.
2.2 Linear Actuators
Linear actuators produce straight-line motion. Most humanoid robots use planetary roller screws to convert motor rotation into linear movement.
Compared with rotary actuators, linear actuators offer:
-
higher positioning accuracy
-
stronger rigidity
-
smoother force transmission
Because of these features, linear actuators are often used in areas requiring precise control, such as knees, ankles, and torso mechanisms.
2.3 Case Study: Tesla Optimus
To better understand this combination, consider Tesla Optimus. This humanoid robot uses:
-
14 linear actuators
-
14 rotary actuators
Through coordinated control, Optimus achieves flexible, human-like movement. As a result, it demonstrates how hybrid actuator architectures are becoming standard in advanced humanoid robots.
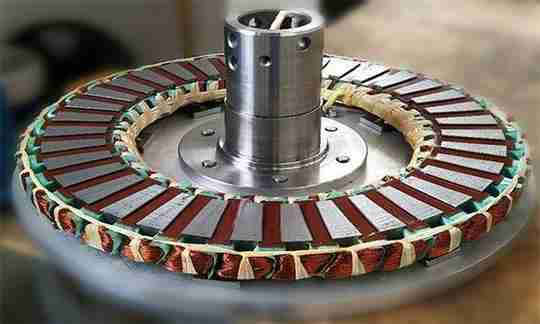
rotational motion
3. The Motor: The Heart of Every Actuator
No matter the actuator type, the motor remains its core component. The motor is responsible for converting electrical energy into mechanical energy. Without the motor, the actuator cannot function.
3.1 What Is a Motor?
A motor is an electrical device that operates based on electromagnetic induction. Simply put, it uses magnetic fields and electric currents to create motion.
Motors can be classified in several ways.
By Function
-
generators
-
electric motors
-
transformers
-
control motors
By Structure and Power Supply
-
transformers
-
rotating electric motors
Rotating electric motors, which include most actuator motors, can be further divided into:
-
power motors
-
control motors
-
signal motors
3.2 Motors in Robot Actuators
In humanoid robots, motors must meet very demanding requirements. For example:
-
fast response time
-
high starting torque
-
low rotational inertia
-
compact size
-
light weight
-
high overload tolerance
Because of these needs, traditional motor designs are reaching their limits. Therefore, new motor structures are gaining attention.
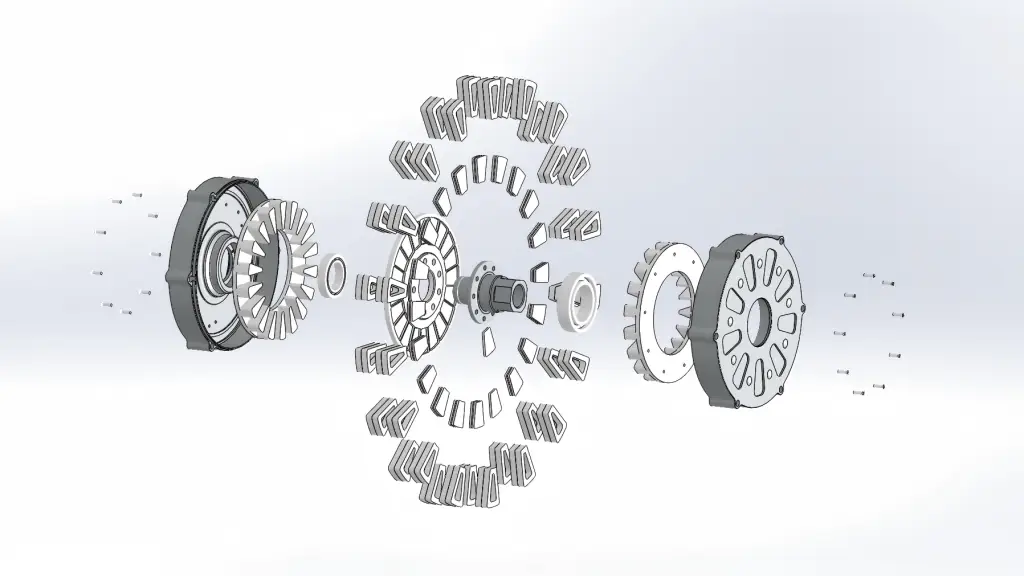
4. Axial Flux Motor Technology: A New Direction in High-Torque Motor Design
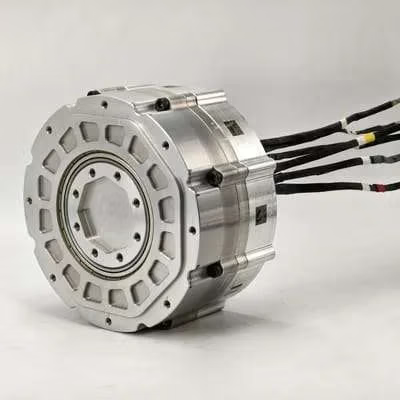
Among emerging motor technologies, axial flux motors stand out. They are also known as disc motors.
4.1 What Is an Axial Flux Motor?
An axial flux motor is a motor where the magnetic flux runs parallel to the motor axis. This is very different from traditional radial flux motors, where the magnetic flux runs radially.
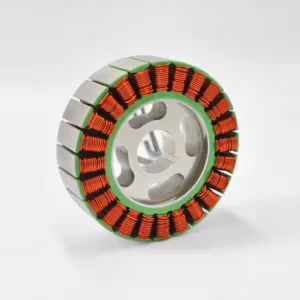
The most important structural feature is that the rotor is located on the side of the stator, not around it. Because of this, axial flux motors have a flat, disc-like structure.
4.2 Structural Advantages
This unique structure brings several benefits:
-
larger effective rotor diameter
-
higher torque output
-
improved power density
-
more flexible mechanical design
As a result, axial flux motors are becoming a key development direction for next-generation high-performance drive systems.
5. Structural Types of Axial Flux Motors
Axial flux motors can be designed in several configurations, depending on stator and rotor arrangement.
5.1 Single Stator / Single Rotor
This structure is simple and compact. However, it suffers from:
-
increased bearing load
-
higher vibration and noise
Therefore, it may affect motor lifespan.
5.2 Single Stator / Dual Rotor
This design uses one stator sandwiched between two rotors. As a result, it offers:
-
very high torque density
-
excellent power output in limited space
This structure is widely used in high-performance traction and aerospace systems.
5.3 Dual Stator / Single Rotor
Here, two stators surround one rotor. This symmetry helps:
-
reduce magnetic imbalance
-
improve operational stability
Because of this, it is commonly used in wind power systems.
5.4 Multi-Stator / Multi-Rotor
By stacking multiple stators and rotors, this structure can output extremely high torque. Therefore, it is suitable for:
-
ship propulsion
-
large wind generators
-
hydroelectric systems

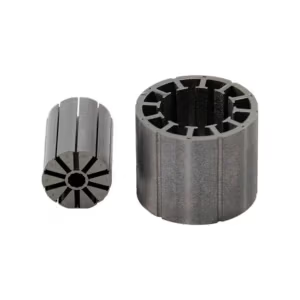
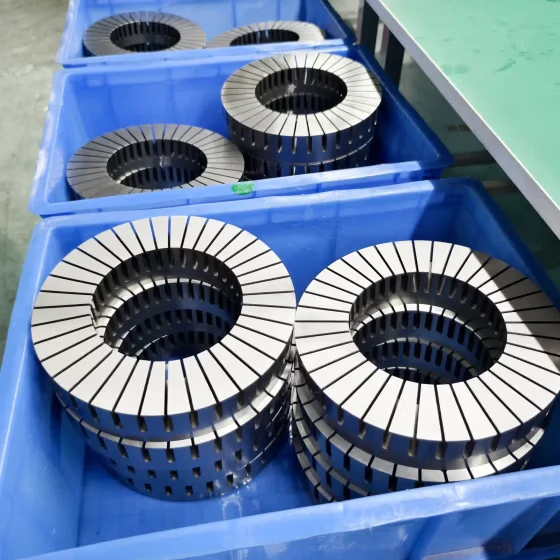
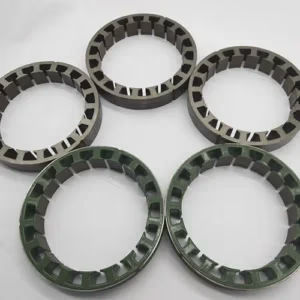
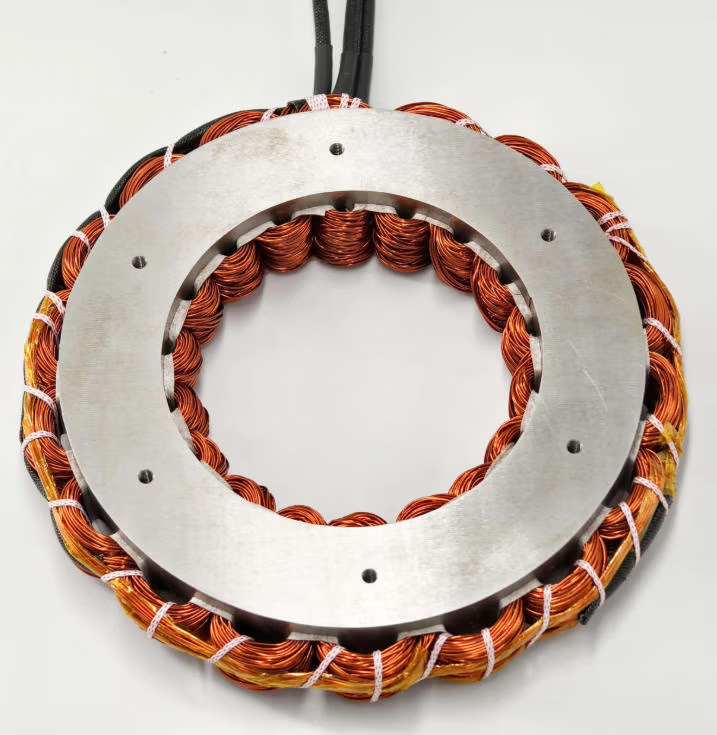 Axial Flux Motors Stator Core
6. Why Axial Flux Motor Technology Enables Higher Torque Density
Torque is the most important output of a motor. It is defined as force × radius.
6.1 Torque Scaling Advantage
For axial flux motors:
-
torque ∝ rotor diameter³
For radial flux motors:
-
torque ∝ rotor diameter²
Because of this difference, axial flux motors can achieve much higher torque under the same material and speed conditions.
6.2 Power Density Relationship
Power is defined as:
P = T × ω
This means that at the same rotational speed, higher torque directly leads to higher power output. Therefore, axial flux motors naturally achieve higher power density.
In practical terms, using the same amount of magnets and copper, axial flux motors can deliver up to four times the torque of traditional radial motors.
7. Performance Breakthroughs and Industrialization
Axial flux motor performance has improved rapidly in recent years. At the same time, industrialization has accelerated.
7.1 Performance Advantages
Under the same power conditions, axial flux motors can achieve:
-
~50% weight reduction
-
~50% axial length reduction
-
wider high-efficiency operating range
-
efficiency >90% over more than 90% of the working area
As a result, they are lighter, thinner, and more efficient.
7.2 Domestic Mass Production Progress
Domestic manufacturers have achieved:
-
large-scale mass production
-
leading patent reserves
-
wide product power coverage (63W–900kW)
Some mass-produced motors now reach 21 kW/kg in power density. This marks a major breakthrough in localization and commercialization.
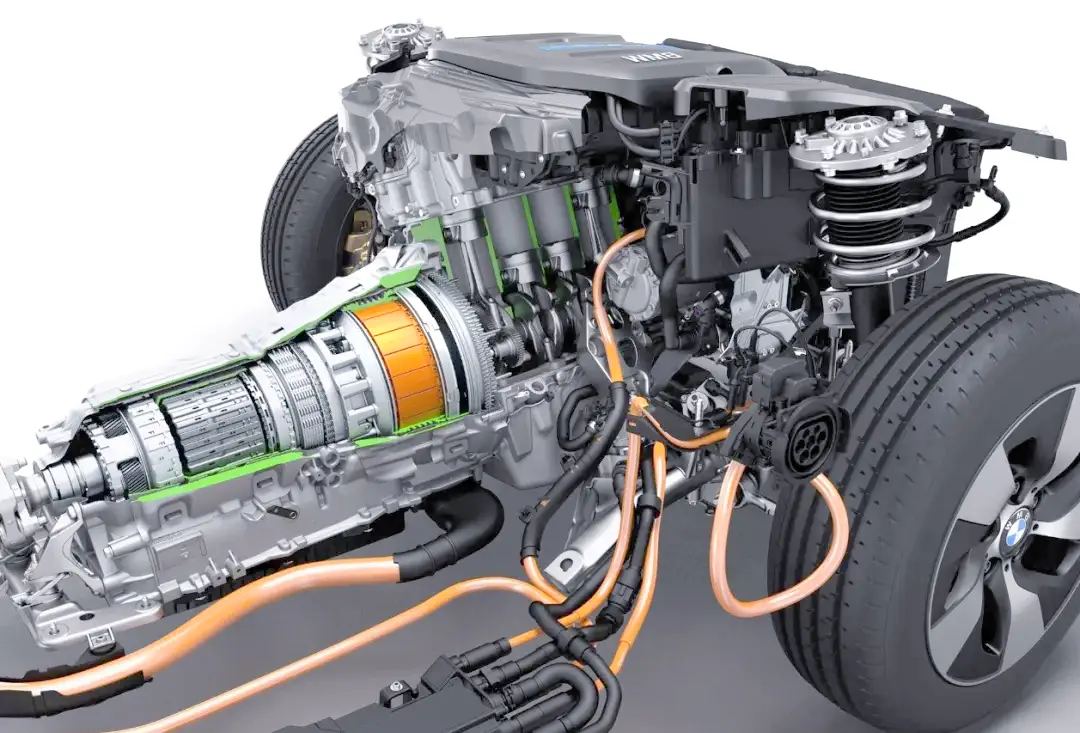
robotic actuator motor layout
8. Axial Flux Motors as a Strategic Technology
Axial flux motors are no longer just a research topic. Instead, they represent a strategic frontier in electric drive systems.
8.1 Industry Layout
Currently, development is concentrated in:
-
high-tech innovation enterprises
-
university research teams
-
selected listed companies
Collaboration focuses on:
-
advanced materials
-
structural optimization
-
manufacturing processes
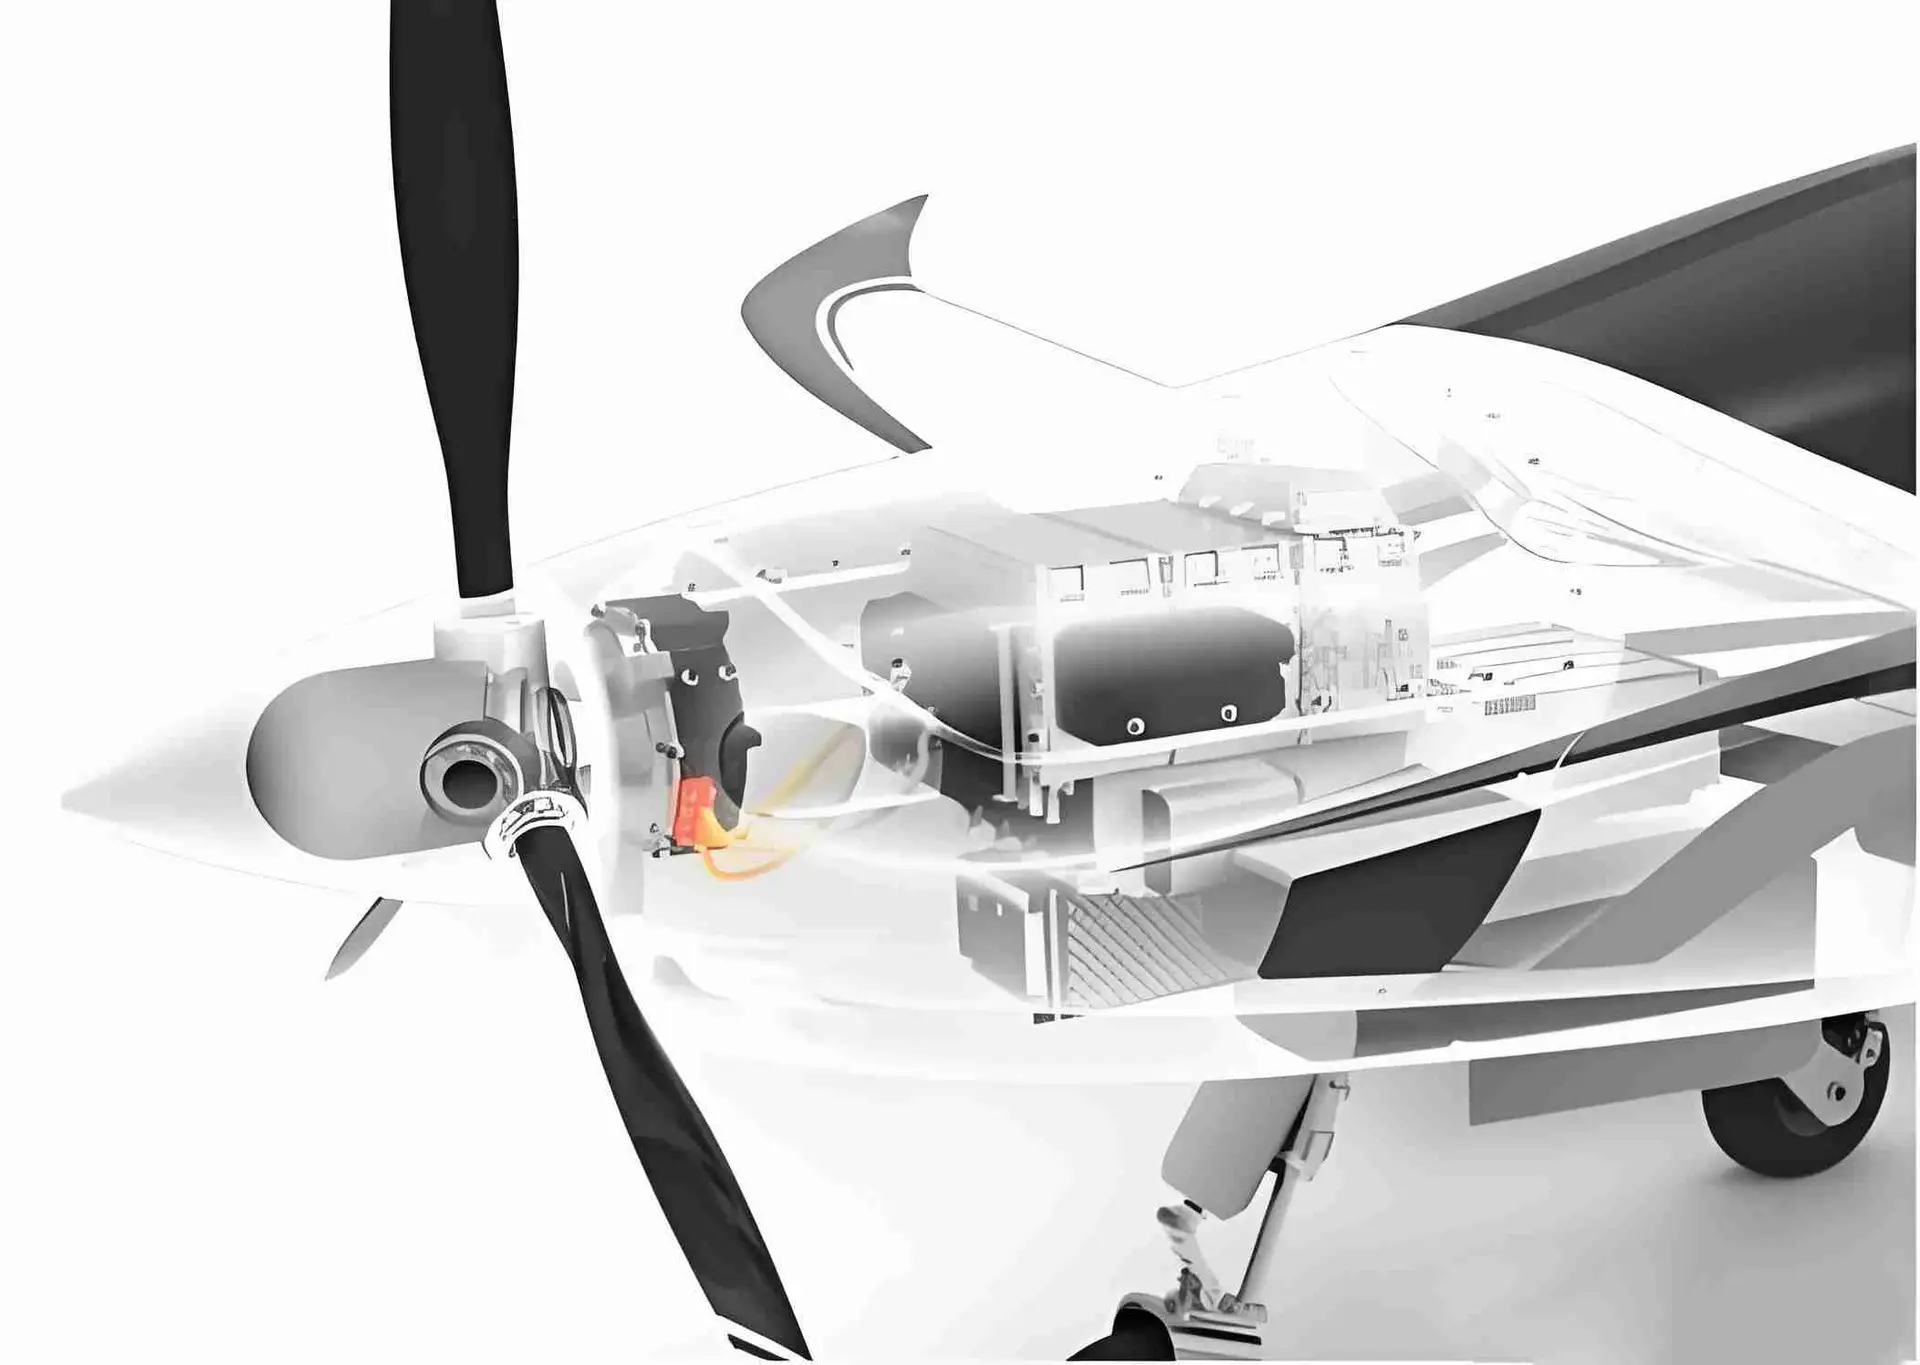 Aircraft-actuator-motor-layout
9. Market Potential of Axial Flux Motors
The axial flux motor market shows strong growth potential.
9.1 New Energy Vehicles and Wheel-Side Drives
Because of their compact size and high torque density, axial flux motors are ideal for:
-
wheel-side motors
-
hub drives
They help reduce unsprung mass while maintaining high output. Therefore, they support large-scale adoption of wheel-side drive systems.
9.2 Aerospace Electrification
In aerospace, weight is critical. Axial flux motors meet this need well.
According to forecasts:
-
aircraft motor market grows from $8.2B (2022) to $12.9B (2027)
-
CAGR: 9.4%
Motors with 5–10 kW/kg power density will dominate, favoring axial flux designs.
10. Axial Flux Motor Technology for Humanoid Robot Actuators
Robot actuators demand:
-
fast response
-
high starting torque
-
low inertia
-
compact size
-
high durability
Axial flux motors meet all these requirements. Therefore, they are an excellent fit for humanoid robot actuators, especially in joints requiring speed, strength, and precision.
Conclusion
Overall, rotary and linear actuators form the core power units of humanoid robots. At the heart of these actuators lies the motor. As performance demands increase, traditional motor designs face growing limitations.
Axial flux motors, with their high torque density, compact structure, and superior efficiency, represent a major leap forward. As industrialization accelerates and applications expand, axial flux motors are set to play a central role in humanoid robots, electric vehicles, aerospace systems, and next-generation electric drives.