brushless motor
Brushless Motor: Comprehensive Analysis of Structure, Principles, and Application Selection
Brushless Motor: Comprehensive Analysis of Structure, Principles, and Application Selection
An Engineering Guide for High Efficiency, High Reliability, and System-Level Optimization
In modern electric drive systems, brushless motor technology has become synonymous with high efficiency, long service life, and precise control performance.
Across application domains such as unmanned aerial vehicles, electric mobility platforms, industrial automation equipment, and high-end consumer electronics, this class of electric drive solutions plays a critical and irreplaceable role at the core of the system.
When compared with traditional brushed designs, electronically commutated motors demonstrate clear advantages in energy conversion efficiency, operational lifespan, maintenance requirements, and overall system integration capability. As a result, an increasing number of engineers and equipment manufacturers are shifting their focus from component-level replacement toward system-level optimization, adopting electronically controlled motor architectures as a long-term technology strategy.
This article delivers a structured and engineering-oriented analysis covering multiple dimensions, including internal structure, operating principles, key technical parameters, application scenarios, and practical selection logic. The goal is to support engineers, technical managers, and procurement decision-makers in making more rational, forward-looking, and application-driven choices in real-world projects.
I. Basic Structural Analysis of Brushless Motors
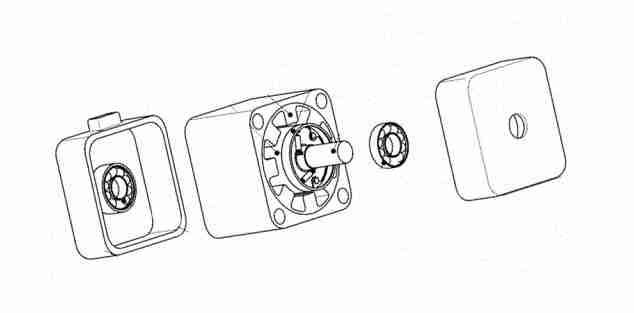
Structurally, brushless motors primarily consist of three major components: the stator, rotor, and position sensor. Together, these elements form the foundation of the motor’s electromagnetic system.
More importantly, these components do not operate independently. Instead, they work in close coordination, enabling precise electronic commutation and stable electromagnetic interaction. As a result, electrical energy is converted into mechanical energy with high efficiency, smooth torque output, and reliable long-term performance.
1. Stator Structure: The Core Carrier of Electromagnetic Energy
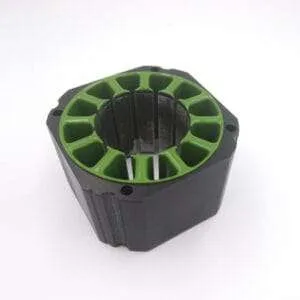
High-efficiency-brushless-motor-for-drone-and-EV-applications
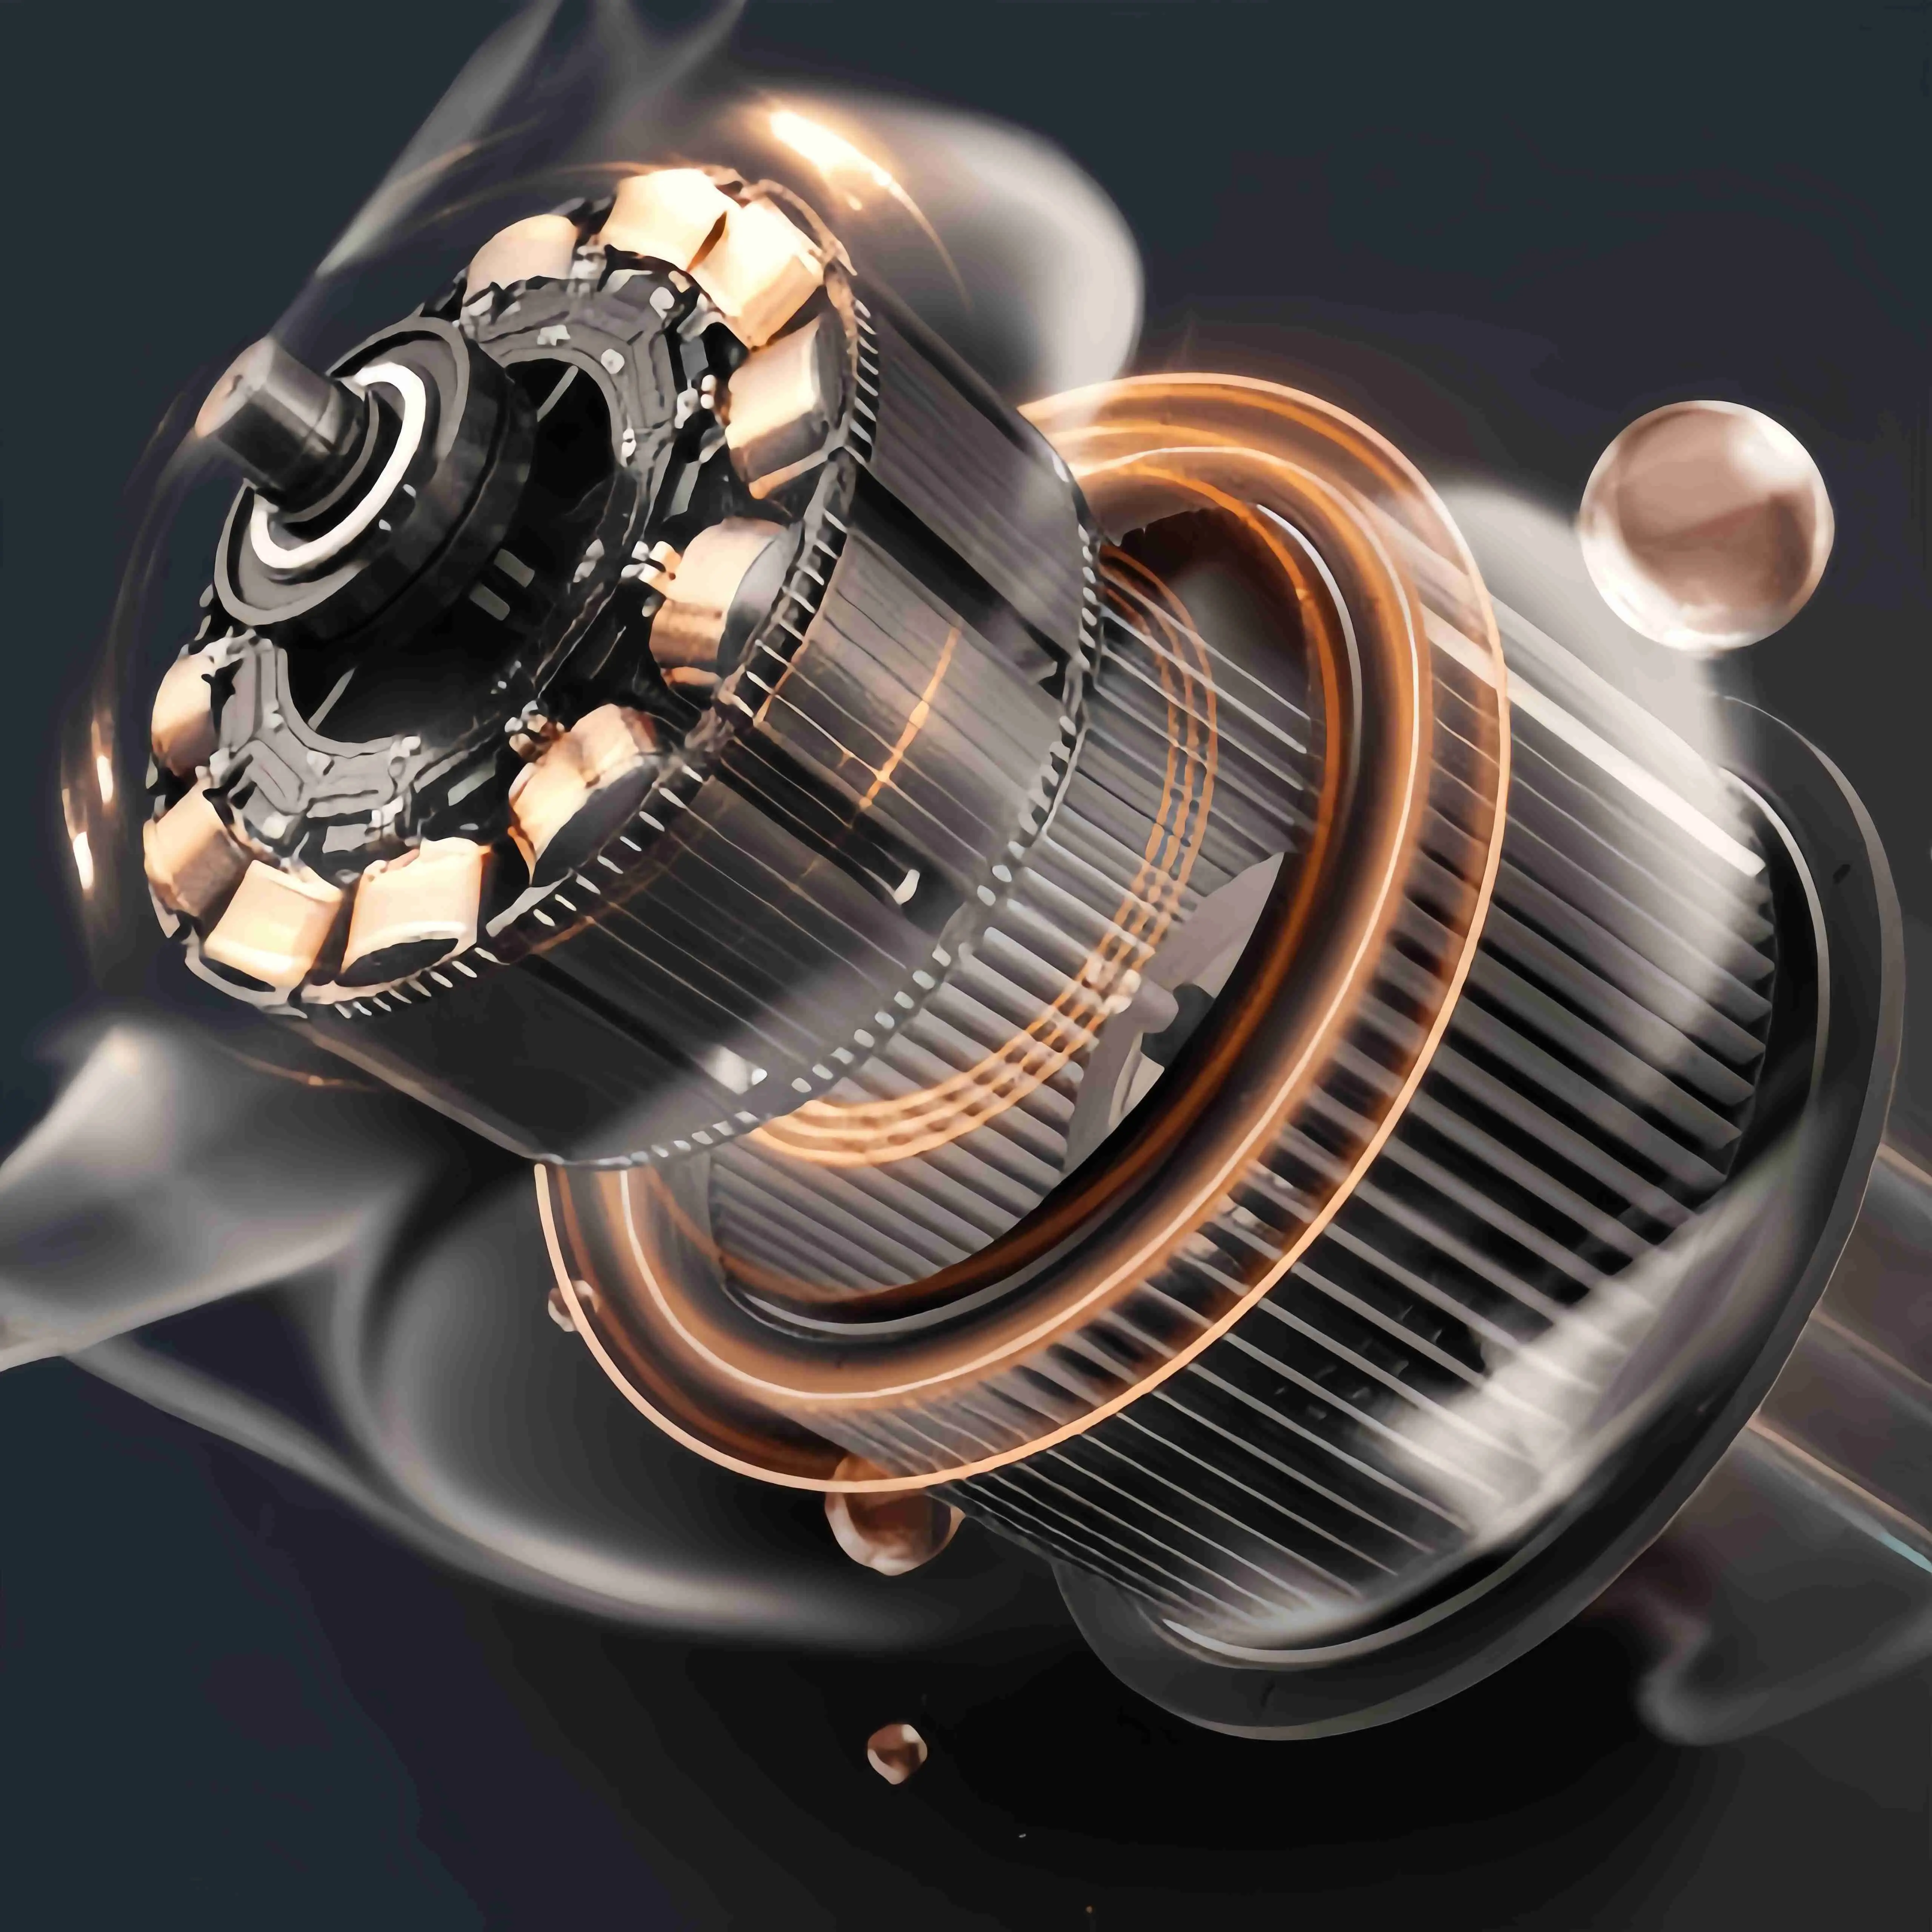
The stator is the non-rotating part of the brushless motor and serves as the core region for generating and regulating electromagnetic energy.
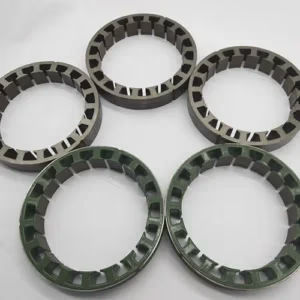
1.1 Stator Core
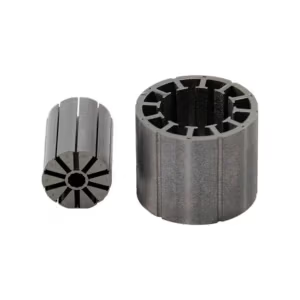
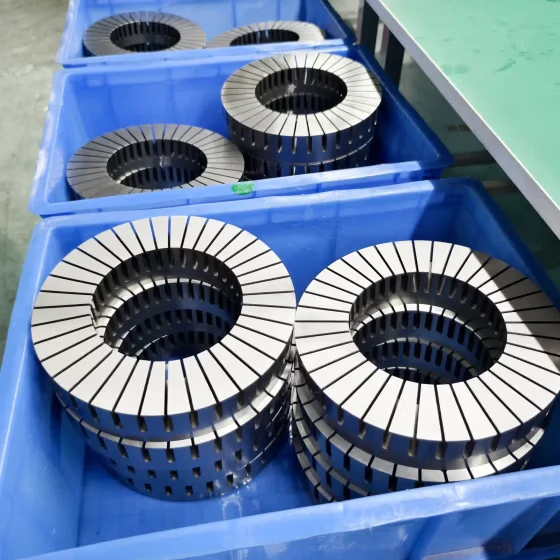
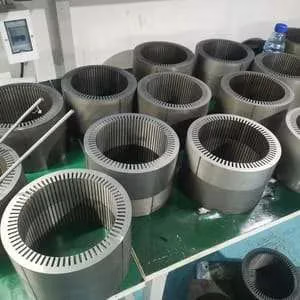
The stator core is typically constructed from multiple laminations of silicon steel sheets, serving key functions including:
- Reducing eddy current losses
- Enhancing magnetic permeability
- Optimizing magnetic flux distribution
- Minimizing heat generation and improving overall efficiency
In high-performance brushless motors, engineers often select low-loss silicon steel materials and employ precise stamping and lamination techniques to further reduce iron losses.
1.2 Stator Windings
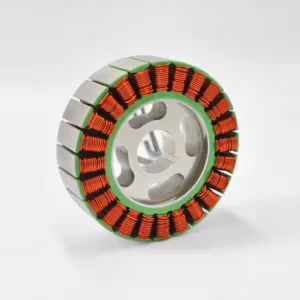
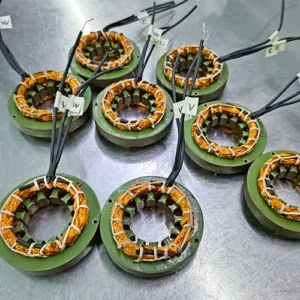
Most brushless motors employ a three-phase winding configuration.
Each phase typically consists of two opposing coil sets arranged symmetrically.
Common winding characteristics include:
- Utilizing high-purity copper wire to enhance conductivity
- Employing either concentrated or distributed windings to suit different application requirements
- Configurable as Y-type (star) or **Δ-type (delta)** connections
Different winding configurations directly impact the motor’s starting characteristics, torque curve, efficiency range, and temperature rise performance.
2. Rotor Structure: The Key Component for Torque Output
The rotor is the only rotating part in a brushless motor, primarily converting electromagnetic force into mechanical output.
2.1 Permanent Magnet Materials
Brushless motors typically employ permanent magnet rotor structures, with the most common magnet materials including:
- Neodymium iron boron (NdFeB)
- Samarium cobalt (SmCo, for high-temperature applications)
Among these, neodymium iron boron is most prevalent in industrial and consumer applications due to its high magnetic energy product and power density.
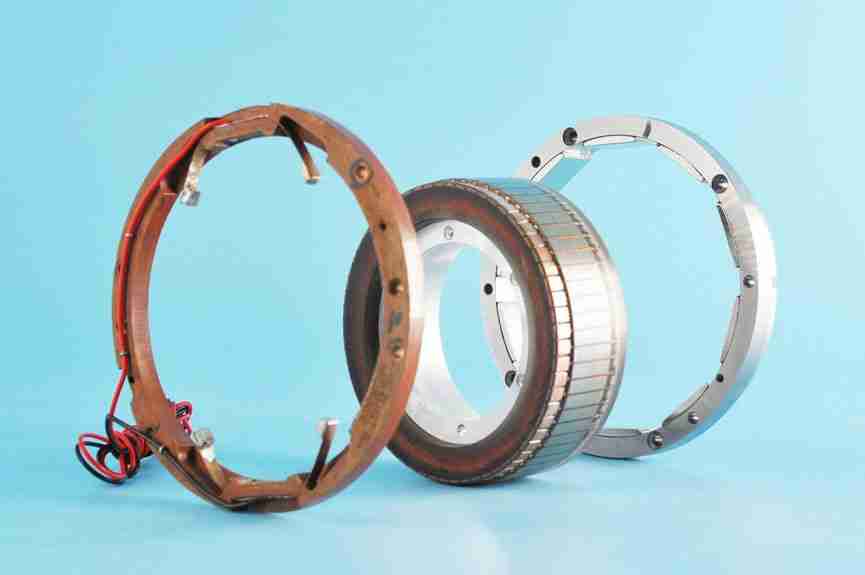
2.2 Inrunner and Outrunner Designs
Structurally, brushless motors can be categorized as:
- Inrunner
- Outrunner
Inrunner Brushless Motor
- Rotor positioned inside the stator
- High rotational speed
- Rapid response
- Commonly used in industrial automation, power tools, and similar applications
Outrunner Brushless Motor
- Rotor encased outside the stator
- High rotational inertia
- High torque density
- Widely used in drones, gimbals, and direct-drive systems
During engineering selection, rotor structure is often directly tied to the application scenario.
3. Position Detection System: Foundation of Precise Control
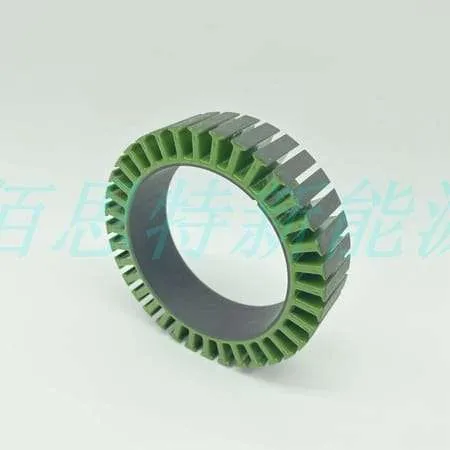
Brushless-motor-internal-structure-showing-stator-and-rotor
The “brushless” nature of brushless motors hinges on electronic commutation.
This electronic commutation requires precise identification of the rotor’s position.
3.1 Hall Sensor
The most common solution is the Hall effect sensor, offering advantages including:
- Mature structure
- Stable startup
- Simple control logic
Hall sensors continuously detect rotor pole positions and feed back signals to the controller.
3.2 Sensorless Control
In some cases, especially in high-end or cost-sensitive applications, sensorless control is used. Instead of relying on physical sensors, rotor position is estimated by detecting back EMF (back electromotive force). As a result, the system can reduce hardware complexity and cost. At the same time, this approach helps improve reliability by eliminating sensor-related failure points.
This approach offers:
- Simpler structure
- Lower cost
- Higher reliability (no additional components)
However, it demands more sophisticated control algorithms during low-speed operation and startup.
II. Detailed Explanation of Brushless Motor Operation
1. Transition from Mechanical Commutation to Electronic Commutation
Traditional brushed motors rely on mechanical brushes and commutators for current switching, which presents the following issues:
- Friction loss
- Electrical sparks
- High noise levels
- Limited lifespan
Brushless motors, in contrast, employ entirely electronic commutation. The controller precisely controls the energization sequence of the stator windings.
2. Basic Process of Electronic Commutation
The operation of a brushless motor typically involves several sequential steps. First, the rotor position is detected. This is done by acquiring rotor angle information via Hall sensors or through algorithms. Next, the controller evaluates the received data. Based on this information, it determines which stator phase requires excitation.
Then, the stator windings are energized. Specifically, the current direction is switched according to the programmed sequence. As a result, a rotating magnetic field is formed. Consequently, the stator magnetic field continuously rotates. Following this, the rotor’s permanent magnets rotate along with the magnetic field, thus outputting mechanical energy.
Finally, this continuous and controllable process enables the motor to achieve high efficiency, low vibration, and stable output. In addition, by maintaining precise synchronization between the rotor and stator, the motor ensures reliable performance even under varying loads and operating conditions. Overall, each step works in concert to maximize energy conversion and operational stability.
III. Core Performance Advantages of Brushless Motors
Structural and operational advantages position brushless motors to excel in multiple key performance metrics.
1. High-Efficiency Operation
- Eliminates brush friction losses
- Losses concentrated within controllable ranges
- Easily optimized efficiency range through control strategies
2. High Power Density
- Permanent magnet rotor generates stronger magnetic field
- Smaller size, greater output
- Suitable for lightweight and compact designs
3. Long Lifespan and Low Maintenance
- No mechanical commutation components
- Minimal wear
- Significantly reduced maintenance costs
4. Precise Control Capability
- Supports vector control (FOC)
- High precision in speed and torque regulation
- Suitable for complex operating conditions and dynamic loads
IV. Primary Application Areas of Brushless Motors
1. Drones and Aerial Systems
In multirotor drones, logistics drones, and industrial inspection platforms, brushless motors have become standard equipment due to their:
- High power-to-weight ratio
- Rapid response
- High reliability
2. Electric Vehicles and New Energy Systems
Brushless motors are extensively used in:
- Drive systems
- Cooling fans
- Power steering
- Water pumps and compressors
Their high efficiency directly impacts the vehicle’s overall range.
3. Industrial Automation and Robotics
In robotic joints, servo systems, and precision machine tools, brushless motors deliver:
- Stable output
- High positioning accuracy
- Long-term continuous operation capability
4. Consumer Electronics and Home Appliances
In sectors like vacuum cleaners, power tools, and smart home appliances, brushless motors are progressively replacing traditional motor solutions.
V. Key Selection Parameters for Drone Applications
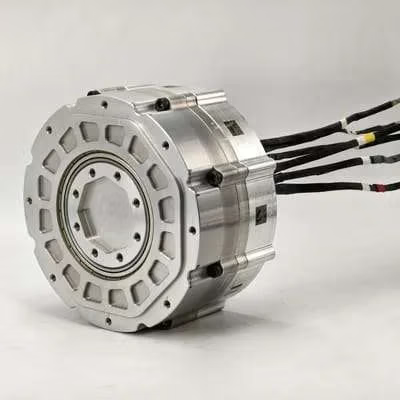
Industrial-brushless-motor-with-electronic-commutation-system
Motor selection is particularly critical in drone systems.
1. Motor Type Selection
- External Rotor: High torque, suitable for direct-drive propellers
- Internal Rotor: High RPM, suitable for geared drives
2. Understanding KV Values
KV value indicates no-load RPM per volt (RPM/V).
- High KV: High speed, small propellers, racing scenarios
- Low KV: Large propellers, heavy loads, long endurance
3. Size and Weight
Directly impacts thrust-to-weight ratio, flight efficiency, and overall design.
4. ESC Compatibility
Must match:
- Voltage rating
- Current capacity
- Control Protocol
VI. Engineering Approach for System-Level Optimization
In practical projects, brushless motors should not be treated as “individual components” but designed and optimized as part of a complete drive system.
Key optimization areas include:
- Motor + Controller Co-design
- Thermal Management and Structural Integration
- Material and Manufacturing Process Optimization
- Application-Specific Customization
Conclusion: Brushless motors remain the long-term core solution for high-efficiency electric drive systems.
With continuous advances in materials, control methods, and manufacturing processes, brushless motors are therefore able to push efficiency, power density, and reliability to higher levels. At the same time, these improvements make motor systems more compact, stable, and easier to integrate into complex equipment.
Moreover, for equipment manufacturers serving the EU and North American B2B market, a deeper understanding of motor structure and operating principles is becoming increasingly important. In addition, when this knowledge is combined with system-level optimization tailored to specific application needs, overall system performance can be improved more effectively. As a result, manufacturers can reduce risk, improve product consistency, and shorten development cycles. Ultimately, this approach plays a key role in building long-term technical and commercial competitiveness.
In the future, brushless motors will not only serve as a drive solution but also as the core foundational module of intelligent electric drive systems.