 brushless motor
Comprehensive Analysis of Axial-Field and Radial-Field Motors
Comprehensive Analysis of Axial-Field and Radial-Field Motors
Structural Principles, Performance Comparison, and Application Trends
In the field of electrical engineering, the direction of magnetic flux is one of the core factors distinguishing motor types.In most traditional motors, magnetic flux traverses the air gap radially, circulating between the stator and rotor. Such motors are commonly referred to as radial field motors.However, when magnetic flux no longer flows radially but instead traverses the air gap axially along the motor’s axis, the motor is defined as an axial field motor. In industrial applications, axial field motors are also frequently termed disc motors.With the rapid development of new energy, electric vehicles, marine propulsion systems, and high power density applications, axial field motors are increasingly becoming a key direction in high-end motor design.
I. Fundamental Differences Between Radial Field Motors and Axial Field Motors
First, there are essential differences in the magnetic path.
Magnetic flux traverses the air gap radially, forming a closed magnetic circuit between the rotor and stator.
This represents the most mature and widely adopted configuration in current industrial applications.
Magnetic flux flows axially, entering the stator from the rotor or vice versa.
This configuration features shorter magnetic paths and a flatter structure, making it suitable for high torque density designs.
Due to these differing magnetic flux paths, both motor types exhibit distinct characteristics in structural layout, power density, manufacturing methods, and application scenarios.
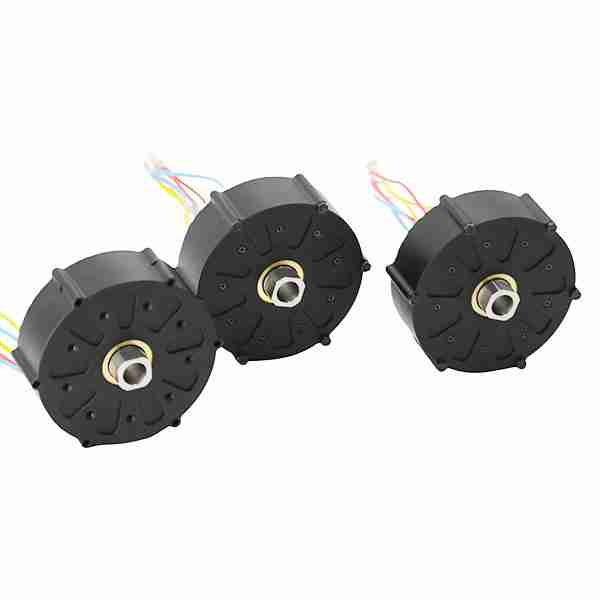
II. Basic Structural Forms of Axial Field Motors
- Single-Stator Single-Rotor Structure
- Dual-Stator Single-Rotor Structure
Both configurations can be regarded as a “basic power unit.”
By axially connecting multiple identical units in series, power ratings can be linearly increased without significantly expanding the diameter.
III. Industrial Development History of Axial Field Motors
In reality, axial field motors are not a new technology.
As early as the 1960s, this concept was applied in the automation industry. At that time, engineers developed drive systems with various power ratings through modular design to meet the needs of different equipment.
By the 1990s, axial field motors saw further advancement in naval ship propulsion systems.
During this phase, their power ratings even reached the megawatt level, fully validating the structure’s feasibility in high-power applications.
IV. Actual Structural Characteristics of Axial Field Motors
1. Stator Core Structure
The stator core of an axial magnetic field motor typically employs a radially stacked structure.
Viewed from above, its form resembles multiple concentric rings.
2. Relationship Between Permanent Magnets and Slot Profile
Since permanent magnets are often fan-shaped, their cross-section facing the air gap gradually increases radially.
Therefore, the following design principles are commonly adopted in engineering practice:
Maintain constant stator slot width
Stator tooth width gradually decreases from outer to inner regions
This tooth-slot configuration effectively ensures:
More uniform radial distribution of magnetic flux density in the teeth
Significantly reduced risk of localized magnetic saturation
Enhanced motor efficiency
V. Comparative Mechanical Characteristics of Different Axial Field Structures
Limitations of Single-Stator Single-Rotor Configuration
Single-Stator Single-Rotor Axial Field Motors Present the Following Issues:
- Significant magnetic pull force exists between the stator and permanent magnets
- Machining or assembly errors readily introduce unbalanced forces
- Higher demands are placed on bearings and mechanical structures
Advantages of Dual-Stator Single-Rotor and Dual-Rotor Single-Stator Structures
In contrast:
- Dual-Stator Single-Rotor Configuration
- Dual-Rotor Single-Stator Configuration
Virtually eliminate the aforementioned magnetic pull imbalance issues.
Additionally, in the dual-stator single-rotor configuration:
- Only the stator possesses a yoke
- The rotor typically lacks a yoke
Power density significantly exceeds single-stator designs due to increased stator participation in energy conversion.

Axial-field-motor-single-stator-single-rotor-design
VI. Manufacturing Challenges and Process Evolution
For an extended period, laminate processing and assembly remained the primary bottlenecks in axial field motor manufacturing.
Key challenges included:
- Complex laminate geometries
- High assembly precision requirements
- Difficult batch consistency control
However, with the maturation of the following technologies:
- High-precision stamping dies
- Laser cutting and wire cutting techniques
- Automated stacking processes
Manufacturing difficulties for axial field motors have been substantially reduced.
VII. Why Radial Field Motors Remain Dominant
Undeniably, radial field motors still hold an overwhelming market advantage.
Key reasons include:
- Mature manufacturing processes
- Simplified assembly workflows
- Highly developed supply chains
- Easier cost control
Consequently, radial field motors remain the preferred solution in most general industrial applications.
VIII. Core Advantages
Nevertheless, axial field motors possess irreplaceable advantages:
- Higher torque density
- Shorter magnetic circuit
- More compact axial dimensions
- Better suited for high power density applications
Consequently, their adoption is rapidly expanding in these fields:
- Electric vehicle drive systems
- Marine propulsion systems
- Aviation electric propulsion
- High-end industrial servo systems
IX. Comparative Analysis of Five Typical Motor Structures
To provide a clearer understanding of structural differences, the following section systematically compares five typical motor types.
All motors in the comparison operate as **permanent magnet brushless DC motors (BLDC)**.
A: Traditional Radial Field Brushless DC Motor
- Permanent magnets mounted on a cylindrical rotor
- Rotor rotates within fixed stator windings
- Stator core laminated from electrical silicon steel sheets
- Distributed winding configuration
- Mature structure with widest application
B:Axial Field Single-Air-Gap Motor
- Single air gap
- Rotor positioned on one side of the stator
- Magnetic flux traverses the air gap axially
- Flatter structure
C:Axial Field Double-Air-Gap Motor
- One stator arranged on each side of the rotor
- Two air gaps present
- Symmetrical magnetic force
- Higher power density
D: Slotless Single-Air-Gap Axial Field Motor
- Stator unslotted
- Toothless structure
- Larger air gap
- Requires high magnetic energy product rare earth permanent magnets
- Higher cost, limited operating temperature
Although the slotless structure completely eliminates cogging torque, its application scope is narrowing with advancements in modern cogging torque mitigation techniques.
E: Slotless Double-Air-Gap Axial Field Motor
- Stator unslotted
- Rotor without yoke
- Permanent magnet flux passes through two air gaps
- Structure similar to Type C
- Superior overall performance
X. Operating Conditions and Parameter Settings
To ensure fair comparison, all motors meet the following conditions:
Output shaft power range
- 0.25 kW
- 1 kW
- 3 kW
- 5 kW
- 10 kW
Rated DC supply voltage: 375 V
Rated speed: 1000 r/min
Induced electromotive force: Trapezoidal wave
Permanent magnet material: Sintered neodymium iron boron
Drive method: Three-phase six-state inverter
Uniform parameter settings ensure high comparability between different structures.

Axial-field-motor-structure-and-magnetic-flux-direction
XI. Comprehensive Conclusions and Application Recommendations
Considering structural, performance, manufacturing, and cost factors, the following conclusions are drawn:
Radial Field Motors
- Suitable for large-scale general-purpose applications
- Preferred choice for cost-sensitive markets
Axial Field Motors
- Better suited for high torque density
- High power density
- Space-constrained applications
In the future, as manufacturing costs continue to decline, axial field motors are expected to gain broader adoption in EVs, electric propulsion, and high-end industrial sectors.