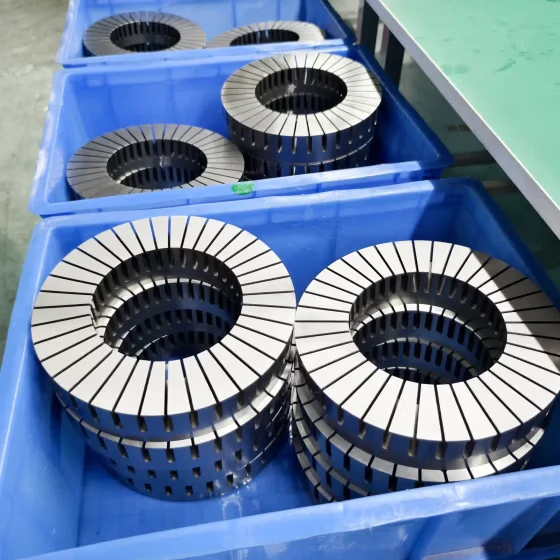
brushless motor
How Robot Joint Motor Stators Improve Precision, Torque, and Efficiency?
How Robot Joint Motor Stators Improve Precision, Torque, and Efficiency?
As industrial robots, collaborative robots, and humanoid robots continue to evolve, motion accuracy and power density have become critical performance indicators. In this context, robot joint motors play a decisive role. At the heart of every joint motor lies a key component: the robot joint motor stator.
Simply put, the stator is not just a passive structure. Instead, it directly defines how precisely a robot moves, how much torque it can deliver, and how efficiently it converts electrical energy into mechanical output. Therefore, improving stator design and manufacturing quality has become a core focus for robot manufacturers and system integrators across Europe and North America.
In this article, we take a deep and practical look at how robot joint motor stators improve precision, torque, and efficiency, covering design principles, materials, manufacturing processes, application scenarios, and future trends. At the same time, we connect technical performance with real-world industrial needs, helping OEMs and automation companies make better sourcing decisions.
What Is a Robot Joint Motor Stator?
articulated robotic arms
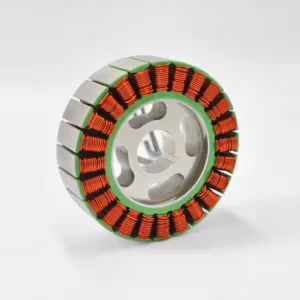
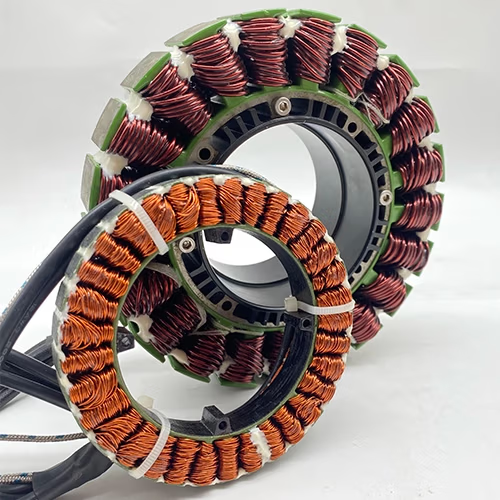
A robot joint motor stator is the stationary part of the motor responsible for generating a controlled electromagnetic field. This magnetic field interacts with the rotor, creating motion and torque.
Unlike conventional motors, joint motors operate in limited spaces and under constantly changing loads. Therefore, their stators must deliver:
-
Stable magnetic flux
-
High precision at low speed
-
High torque density
-
Low loss and low heat generation
In most robotic applications, stators are built from laminated silicon steel cores combined with precision windings. Each design choice, from lamination thickness to slot geometry, directly affects motor behavior.
As a result, stator quality is no longer a secondary consideration. Instead, it has become a defining factor in robot performance.
Why Robot Joint Motors Demand Higher Stator Performance
Robot joints face very different challenges compared to standard industrial motors. For example, a robotic arm joint must start, stop, reverse, and hold position with extreme accuracy.
Therefore, robot joint motor stators must meet several strict requirements:
-
High positioning accuracy and repeatability
-
Smooth torque output with low cogging
-
Compact size and lightweight structure
-
High efficiency under partial loads
-
Long-term reliability in continuous operation
Because of these demands, traditional motor stator designs often fall short. Consequently, specialized stator solutions have emerged for robotic joints.
How Stator Design Improves Precision
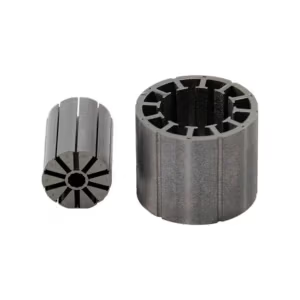
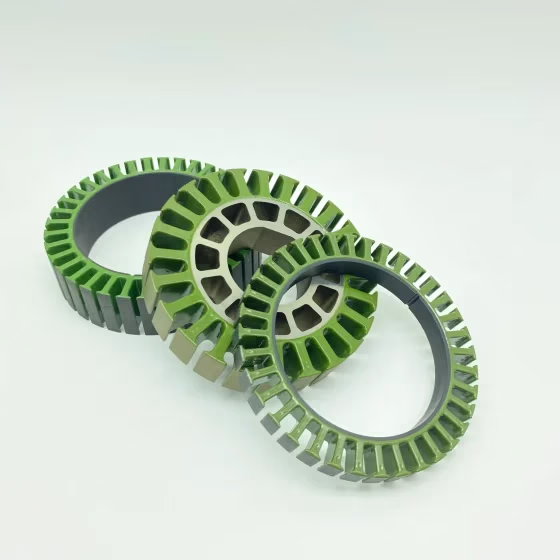
CNC and laser cut stator core for robotic motor systems
Material Selection as the First Step
First of all, precision starts with material choice. High-grade low-loss silicon steel laminations form the foundation of accurate magnetic performance.
By using materials with high permeability and low core loss, stators can produce a more stable and predictable magnetic field. As a result, positioning errors decrease, especially at low speeds.
Moreover, thin laminations with high-quality insulation coatings reduce eddy currents. This further stabilizes magnetic behavior and improves repeatability.
Optimized Magnetic Path Design
Next, electromagnetic design plays a key role. Through optimized slot shape, tooth geometry, and air-gap design, engineers can achieve a more uniform magnetic field.
Consequently, torque ripple is reduced. This leads to smoother motion and higher control accuracy, which is essential for robotic joints performing delicate tasks.
In addition, proper magnetic path design ensures consistent performance under varying loads and temperatures.
Precision Manufacturing Processes
Even the best design fails without accurate manufacturing. Therefore, advanced production methods such as precision stamping, laser cutting, and CNC machining are critical.
By maintaining tight tolerances during lamination stacking and core assembly, manufacturers ensure that each stator matches its design model. As a result, motors behave consistently from unit to unit.
Meanwhile, strict quality inspections help detect deviations early, preventing performance issues in the field.
How Robot Joint Motor Stators Increase Torque Output
High Slot Fill Factor and Winding Optimization
One effective way to improve torque is to optimize the winding structure. A high slot fill factor allows more copper in the same space, which strengthens the magnetic field.
However, this must be done carefully. Excessive copper increases resistance and heat. Therefore, advanced winding techniques and layout planning are essential.
As a result, torque output increases without sacrificing efficiency.
Advanced Current Control Compatibility
In modern robotic systems, stators must work seamlessly with advanced drive electronics. Through optimized stator design, motors respond better to PWM and vector control strategies.
This allows precise torque control across a wide speed range. Consequently, robot joints deliver strong torque during acceleration and stable holding torque during positioning.
Use of High-Energy Permanent Magnets
Although magnets sit on the rotor, stator design determines how effectively magnetic energy converts into torque. When paired with NdFeB permanent magnets, optimized stators maximize torque density.
This combination is especially important in compact robot joints, where space and weight are limited.
How Stator Design Improves Efficiency
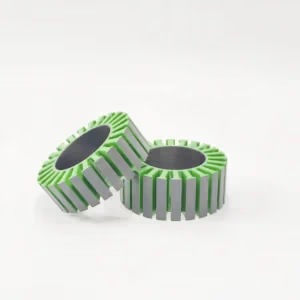
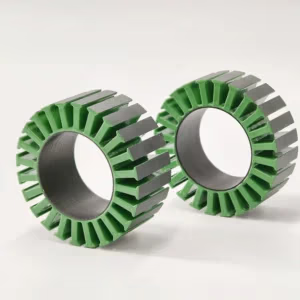
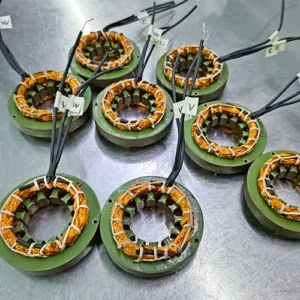
Robot stator for automation and smart manufacturing equipment
Reducing Core and Copper Losses
Efficiency improvement begins with loss reduction. Laminated stator cores significantly reduce eddy current losses compared to solid cores.
At the same time, optimized winding design reduces copper losses. Together, these improvements increase overall motor efficiency.
As a result, robots consume less energy and generate less heat.
Improved Thermal Management
Heat directly affects efficiency and lifespan. Therefore, stator design must support effective heat dissipation.
By optimizing lamination stacking, insulation systems, and cooling paths, stators maintain lower operating temperatures. In high-power applications, air or liquid cooling further improves thermal stability.
Compatibility with Advanced Motor Control
Modern control methods such as FOC and DTC rely on predictable magnetic behavior. High-quality stators provide stable parameters, allowing controllers to operate motors near optimal efficiency points.
Therefore, stator design and control strategy must work together.
Manufacturing Technologies Behind High-Performance Robot Joint Motor Stators
From a production perspective, consistent stator quality requires advanced manufacturing systems:
-
Precision stamping or laser cutting
-
Automated lamination stacking
-
Vacuum annealing to restore magnetic properties
-
Insulation coating to suppress eddy currents
-
Comprehensive electrical and magnetic testing
Each step directly affects final motor performance. Therefore, experienced manufacturers integrate design, tooling, and production under one system.
Application Scenarios Across Robotics Industries
Robot joint motor stators are widely used in:
-
Industrial robot arms
-
Collaborative robots (cobots)
-
Humanoid robots
-
Medical and surgical robots
-
Automated guided vehicles (AGVs)
In each case, stator requirements vary. As a result, custom stator solutions are often necessary to match torque, size, and efficiency targets.
Customization as a Competitive Advantage
In the EU and North American B2B market, customization has become a key purchasing factor. OEMs increasingly demand stators tailored to their specific motor designs.
Custom options include:
-
Lamination thickness and material grade
-
Slot shape and winding layout
-
Inner and outer diameter customization
-
Axial flux or radial flux configurations
Through customization, manufacturers help clients shorten development cycles and improve system performance.
Axial Flux Stator Cores in Robot Joint Motors
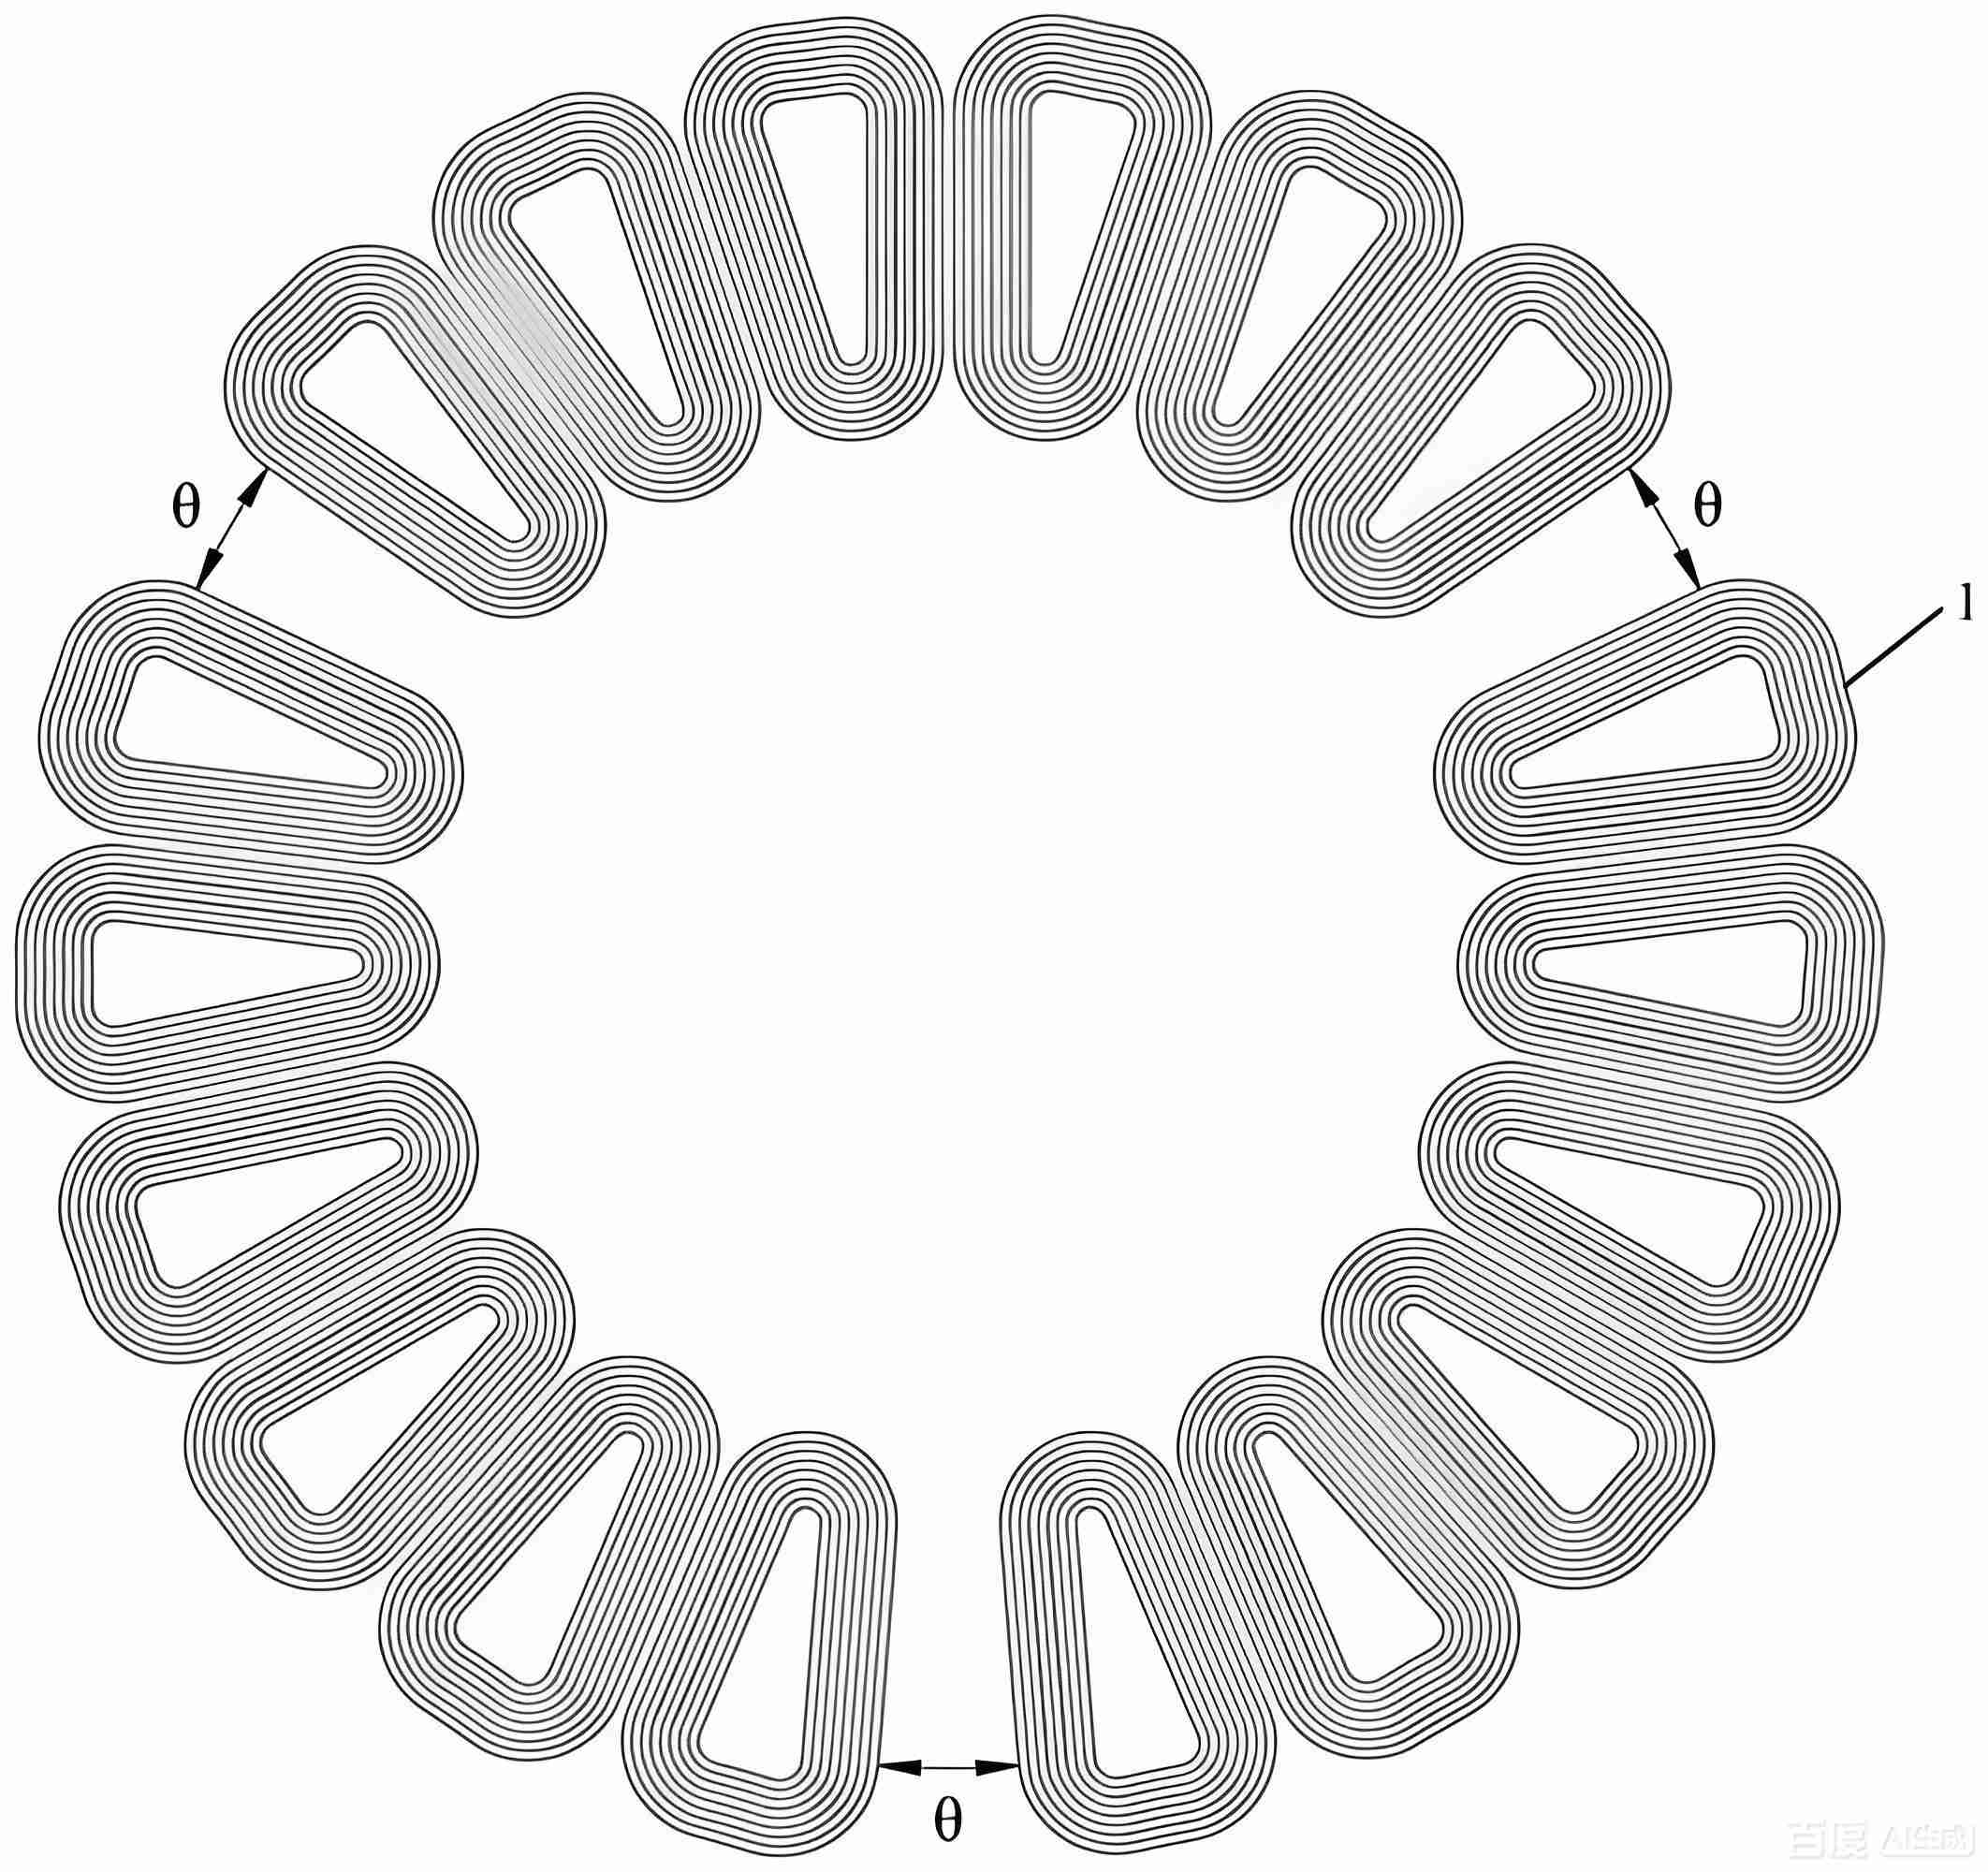
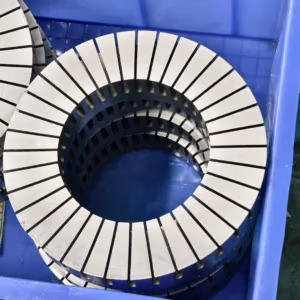
Axial flux stator core for compact robotic motor design
In recent years, axial flux stator designs have gained attention in robotic joints. Compared to traditional radial flux motors, axial flux designs offer:
-
Higher torque density
-
Thinner motor profiles
-
Shorter magnetic paths
Therefore, axial flux stators are ideal for lightweight and compact robot joints. Although manufacturing is more complex, the performance benefits are significant.
Future Trends in Robot Joint Motor Stator Technology
Looking ahead, stator technology will continue to evolve. Key trends include:
-
Higher power density materials
-
Advanced insulation systems
-
Smart manufacturing and digital quality control
-
Integration with AI-driven motor control
As robots become more intelligent and flexible, stators will remain at the center of innovation.
Conclusion
In summary, robot joint motor stators play a decisive role in improving precision, torque, and efficiency. Through optimized materials, electromagnetic design, advanced manufacturing, and intelligent control integration, stators transform robotic performance.
For robot manufacturers and system integrators, choosing a capable stator supplier with strong customization and engineering support is no longer optional. Instead, it is a strategic decision that directly impacts product competitiveness and long-term success.