brushless motor
How to Choose the Right Axial Flux Motor?
How to Select the Right Axial Flux Motor
Selecting an Axial Flux Motor is not only about peak power. Instead, the best choice comes from matching the motor structure to the real working condition. At the same time, heat control, driver matching, and efficiency range all play a major role in long-term performance.
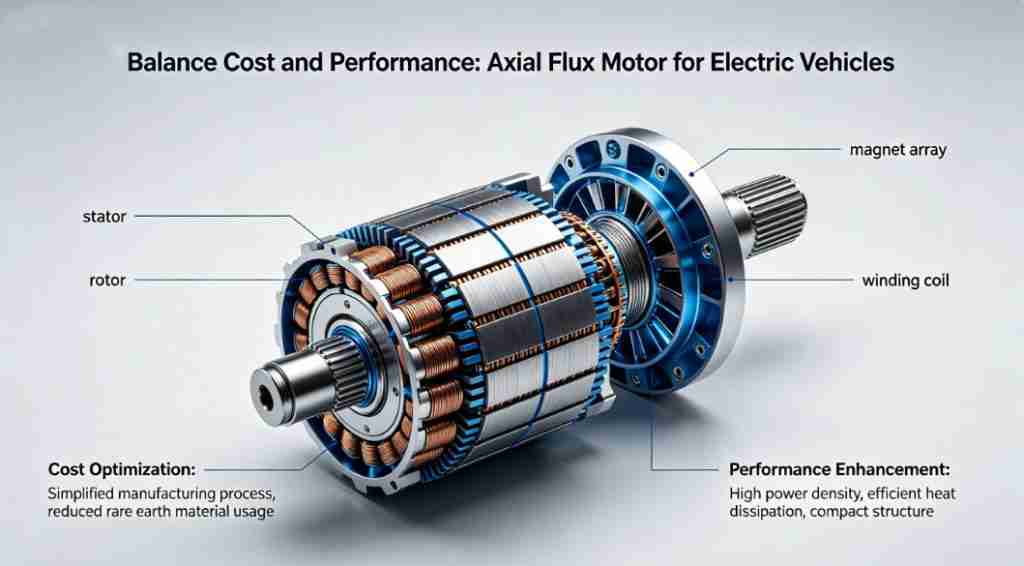
For mostAxial Flux Internal Rotor or YASA topology
high efficiency axial flux motor
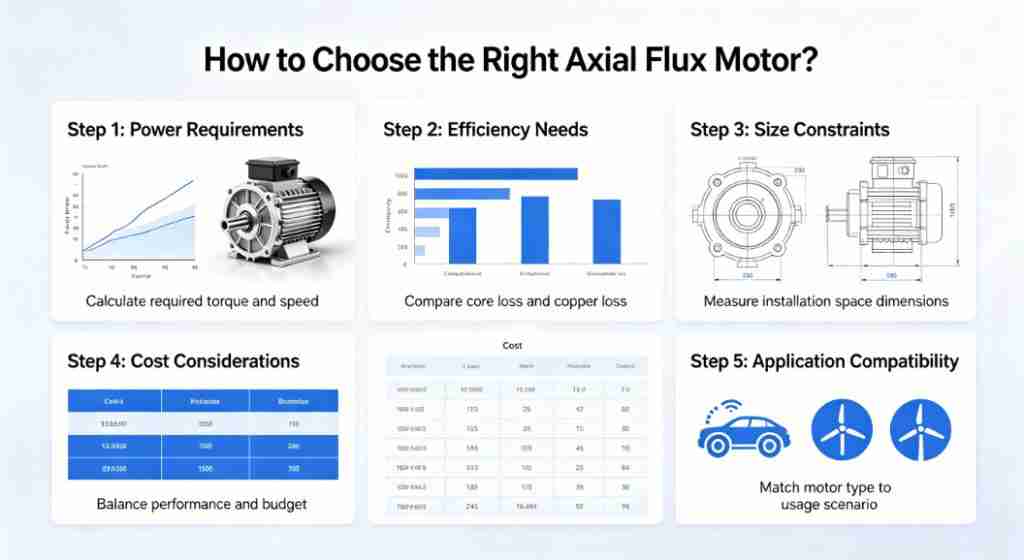
Power and torque → Cooling system → Efficiency → Motor control → Cost balance
As a result, this guide explains how to select the right axial flux motor for electric vehicles, eVTOL aircraft, humanoid robots, wheel-side drive systems, and precision indu
Before selecting any motor, define the real operating targets. Otherwise, it is easy to focus on one strong parameter while ignoring system limits.
For high-performance applications, several factors matter most.
1. Power Density and Torque Density
High power density means more output with less weight. Therefore, it is critical for aerospace systems and eVTOL aircraft.
On the other hand, high torque density matters more in robotic joints, wheel hub motors, and compact servo systems.
Typical targets include:
- General high-performance systems: ≥8 kW/kg
- Aerospace and robotics: ≥12 kW/kg
- Torque density target: ≥60 N·m/L
- Advanced YASA motors: up to 160 N·m/L
Because axial flux motors use a larger effective radius, they can produce higher torque with a smaller package size.
axial flux motor manufacturer
2. Continuous Torque vs Peak Torque
Many suppliers highlight peak torque numbers. However, peak output often lasts only a few seconds.
In real applications, continuous torque is much more important because it determines stable long-term operation.
Therefore:
- Peak torque = overload capacity
- Continuous torque = real usable output
For high-duty systems, always size the motor according to continuous load demand.
3. Dynamic Response
Fast response improves control accuracy. Therefore, low rotor inertia becomes very important in:
- Humanoid robots
- High-speed servo systems
- Precision machine tools
- Aerospace actuators
The YASA structure performs especially well here because it reduces rotational inertia.
As a result, acceleration and deceleration become faster.
axial flux motor for EV
4. Thermal Management
Thermal control directly affects continuous performance. In fact, heat is often the main limit in high-power motor systems.
Therefore:
- Liquid cooling is strongly recommended for high-load applications
- Air cooling only fits low-power or intermittent-duty systems
A good cooling design helps:
- Maintain stable torque
- Protect magnets
- Extend winding life
- Reduce efficiency loss
For demanding systems, target thermal resistance should stay below 0.2°C/W.
5. Installation Space high-speed axial flux motor system
Axial flux motors are usually chosen because of their thin structure.
Therefore, they work very well in:
- Wheel-side drives
- Embedded robotic joints
- Aircraft propulsion systems
- Compact industrial machines
In most cases:
- Axial space is limited
- Radial space is easier to expand
As a result, axial flux structures offer a major packaging advantage.
6. Efficiency Range compact electric drive motor
high torque density motor
Do not focus only on peak efficiency.
Instead, study the full efficiency map.
A good high-performance motor should maintain high efficiency across the full operating range, including:
- Low speed
- Medium load
- Cruise conditions
- Partial load operation
This improves:
- Energy savings
- Battery range
- Heat control
- Overall system stability
II. Choose the Best Axial Flux Motor Topology axial flux permanent magnet motor
The motor topology determines the final limits of torque density, efficiency, cooling performance, and manufacturing cost.
Therefore, selecting the correct structure is one of the most important steps.
1. Single-Stator Single-Rotor (SSSR) advanced axial flux propulsion motor
Structure:
- 1 stator
- 1 rotor
Advantages:
- Simple structure
- Lower production cost
- Easier assembly
Best for:
- Entry-level systems
- Low-power equipment
- Budget-sensitive projects
Limitations:
- Lower torque density
- Higher vibration
- Unbalanced magnetic force
Therefore, this design is not ideal for extreme performance systems.
2. Dual-Stator Single-Rotor (AFIR) industrial axial flux motor manufacturer
Structure:
- 2 stators
- 1 rotor between them
The Axial Flux Internal Rotor design is one of the most balanced choices for industrial use.
Advantages:
- Symmetrical magnetic circuit
- Higher torque density
- Better thermal performance
- Strong structural stability
Best for:
- Electric vehicles
- Wheel-side drive systems
- Industrial servo systems
- Performance motorcycles
Limitations:
- Medium axial size
- Higher assembly precision requirement
However, AFIR motors provide an excellent balance between cost and performance.
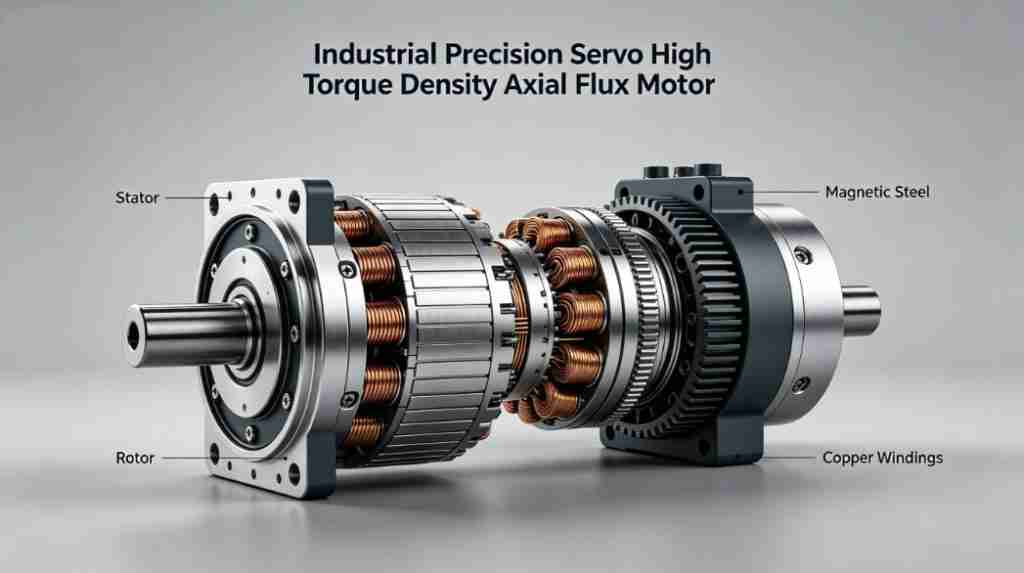
3. Single-Stator Dual-Rotor (YASA) axial flux EV motor technology
axial flux electric motor
Structure:
- 1 yokeless stator
- 2 outer rotors
The YASA structure delivers extremely high performance.
Advantages:
- Very high efficiency
- Extremely high torque density
- Lightweight structure
- Low rotational inertia
- Excellent cooling capability
Best for:
- eVTOL aircraft
- Aerospace propulsion
- Humanoid robots
- High-speed precision systems
Limitations:
- Higher magnet cost
- Complex manufacturing
- Increased material usage
Still, for ultra-high power density, YASA remains one of the strongest solutions available.
4. Multi-Disk Stacked Structure high efficiency axial flux motor solution
Structure:
- Multiple AFIR or YASA units stacked together
Advantages:
- Scalable power output
- Better fault tolerance
- Flexible system expansion
Best for:
- Aerospace power systems
- Megawatt drive platforms
- Heavy electric propulsion
Limitations:
- Large diameter
- High system complexity
- Increased cooling challenge
|
Topology
|
Structure
|
Core Advantages
|
Applicable Scenarios
|
Key Limitations
|
|---|---|---|---|---|
|
Single-Stator Single-Rotor (SSSR)
|
1 stator + 1 rotor
|
Simplest structure, low cost
|
Low power, cost-sensitive scenarios
|
Unilateral magnetic pull, large vibration, low torque density
|
|
Dual-Stator Single-Rotor (AFIR)
|
2 stators clamping 1 rotor
|
Symmetric magnetic circuit, high torque density, excellent heat dissipation
|
Electric vehicles, wheel-side drive, industrial servo
|
Medium axial size, high assembly precision requirement
|
|
Single-Stator Dual-Rotor (YASA)
|
1 yokeless stator + 2 rotors
|
No core loss, ultra-lightweight, highest efficiency, low inertia
|
eVTOL, humanoid robots, high-speed spindles
|
High cost, large permanent magnet consumption
|
|
Multi-Disk Stacked Structure
|
Multiple coaxial AFIR/YASA units
|
Scalable power/torque, strong fault tolerance
|
Megawatt-level drive, aerospace power system
|
Large diameter, high system complexity
|
Selection Conclusion
-
For ultimate power density and lightweight demand: ChooseYASA (Single-Stator Dual-Rotor).
-
For balanced performance and cost: Choose AFIR (Dual-Stator Single-Rotor).
-
For low power and budget-limited scenarios: Opt for the simplified SSSR.