 brushless motor
Stator Assembly, Stator Assembly Manufacturing Method, Motor And Robot
Stator Assembly, Stator Assembly Manufacturing Method, Motor And Robot
The present application relates to the field of robotics technology. Specifically, it concerns a stator assembly, a method for manufacturing the stator assembly, an electric motor, and a robot. It addresses the issue that existing motors cannot simultaneously optimize slot fill rate and core coaxiality.
The stator assembly comprises: a core and at least one movable tooth. The core comprises a ring-shaped yoke and multiple fixed teeth located on the inner side of the yoke. It also includes at least one movable tooth mounting position. Adjacent fixed teeth form tooth slots. The movable tooth is positioned in the movable tooth mounting position. It is detachably connected to the core. The movable tooth and adjacent fixed teeth form tooth slots.
The inclusion of a circular yoke and fixed teeth in the core facilitates single-step stamping. This enhances core coaxiality. Furthermore, the stator assembly’s movable teeth allow for rectangular tooth slots. After winding the coil around both fixed and movable teeth, the coil-wound movable teeth are inserted into their mounting slots. This maximizes slot space utilization and improves slot fill rate.
Technical Field
This application relates to the field of robotics. Specifically, it concerns a stator assembly, a method for manufacturing the stator assembly, a motor, and a robot.
Background Technology
Robots, especially legged robots, require motors with high torque, small size, and light weight. To meet these requirements, motors need a high slot fill factor. The stator assembly is one of the core components of the motor. Factors such as the limited number of slots and wasted slot space in the stator assembly restrict the motor’s slot fill factor. To improve the slot fill factor, existing motors divide the stator core into multiple small blocks. Each block has a fixed tooth. They then assemble these blocks into a ring, resulting in poor coaxiality of the stator core.
Therefore, existing motors cannot simultaneously achieve both high slot fill factor and good core coaxiality.
Content
Structure of the Stator Assembly
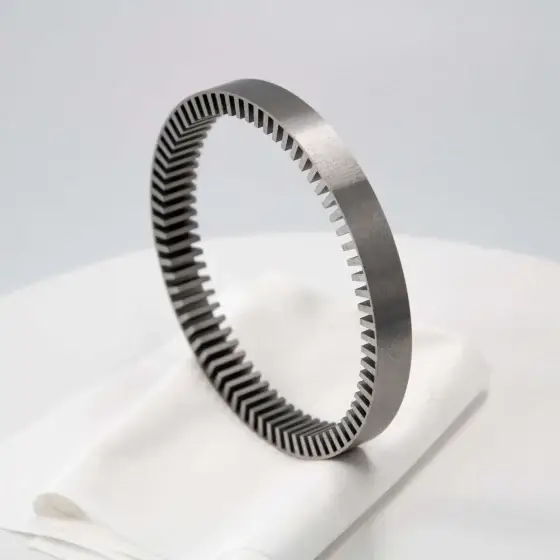
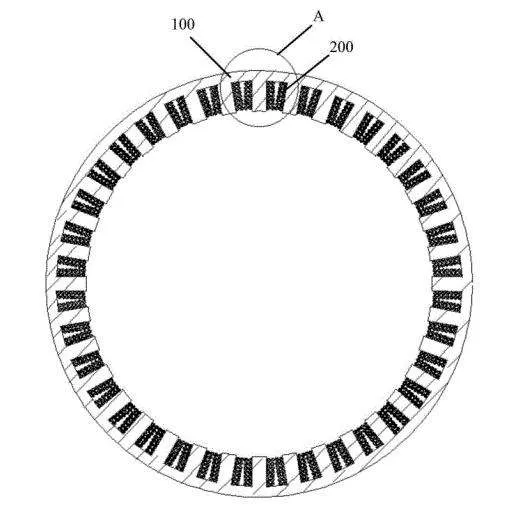
A stator assembly includes an iron core and at least one movable tooth. The iron core consists of a ring-shaped yoke, with several fixed teeth arranged along the inner circumference. There are also one or more mounting positions for movable teeth. Each pair of adjacent fixed teeth forms a tooth slot. A movable tooth fits into its mounting position. It connects to the core in a detachable manner. Once installed, the movable tooth and the adjacent fixed tooth form an additional tooth slot.
Tooth Slot Geometry
The projection of the tooth slot on the end face of the yoke appears as a rectangle. This structure simplifies manufacturing and ensures consistent slot geometry.
Through Slot and Movable Tooth Connection
The inner surface of the yoke includes a through slot that runs axially. A connecting portion on the movable tooth inserts directly into this through slot. In a plane perpendicular to the yoke’s axis, the through slot presents a first trapezoidal shape. Its upper base is near the inner ring and its lower base near the outer ring. The connecting portion shows a second trapezoidal projection, matching the orientation of the through slot. This trapezoidal interface restricts radial displacement of the movable tooth and stabilizes its position in the core.
Coil Arrangement
The stator assembly uses multiple coils wound from conductive wire.These coils mount directly on both the fixed teeth and the movable teeth before final assembly.
Functional Advantages
This design supports one-piece stamping of the iron core, which improves its coaxial accuracy.The movable-tooth structure allows the tooth slots to use a rectangular form factor, increasing usable slot space.Manufacturers can wind coils on every tooth first and then insert each movable tooth into its mounting position.This method maximizes slot utilization and leads to a higher slot fill factor.
Stator Assembly for Motor and Robot Applications